Develop and Verify a Multi-Vehicle Search and Rescue Mission
R2026bThis example demonstrates a requirements-based Model-Based Systems Engineering (MBSE) workflow for a multi-vehicle simulation. It shows how to capture system-of-systems requirements for a search and rescue (SAR) scenario, design a multi-vehicle architecture in System Composer™, simulate the coordinated mission, and verify emergent behaviors that only appear when vehicles interact.
Open Project
Open the asbMultiVehicleSAR project to access all models, requirements, and tests:
openProject('asbMultiVehicleSAR');Mission Scenario
A distressed vessel is adrift at an unknown location. A ground station coordinates four autonomous vehicles — two search aircraft, a loiter drone, and a Coast Guard vessel — through sequential phases: search, detection, drone confirmation, Coast Guard transit, rendezvous, and escort return. Each vehicle is modeled independently in Simulink® using Kinematic Aerospace Actor blocks and composed into a system architecture using System Composer.
System Architecture
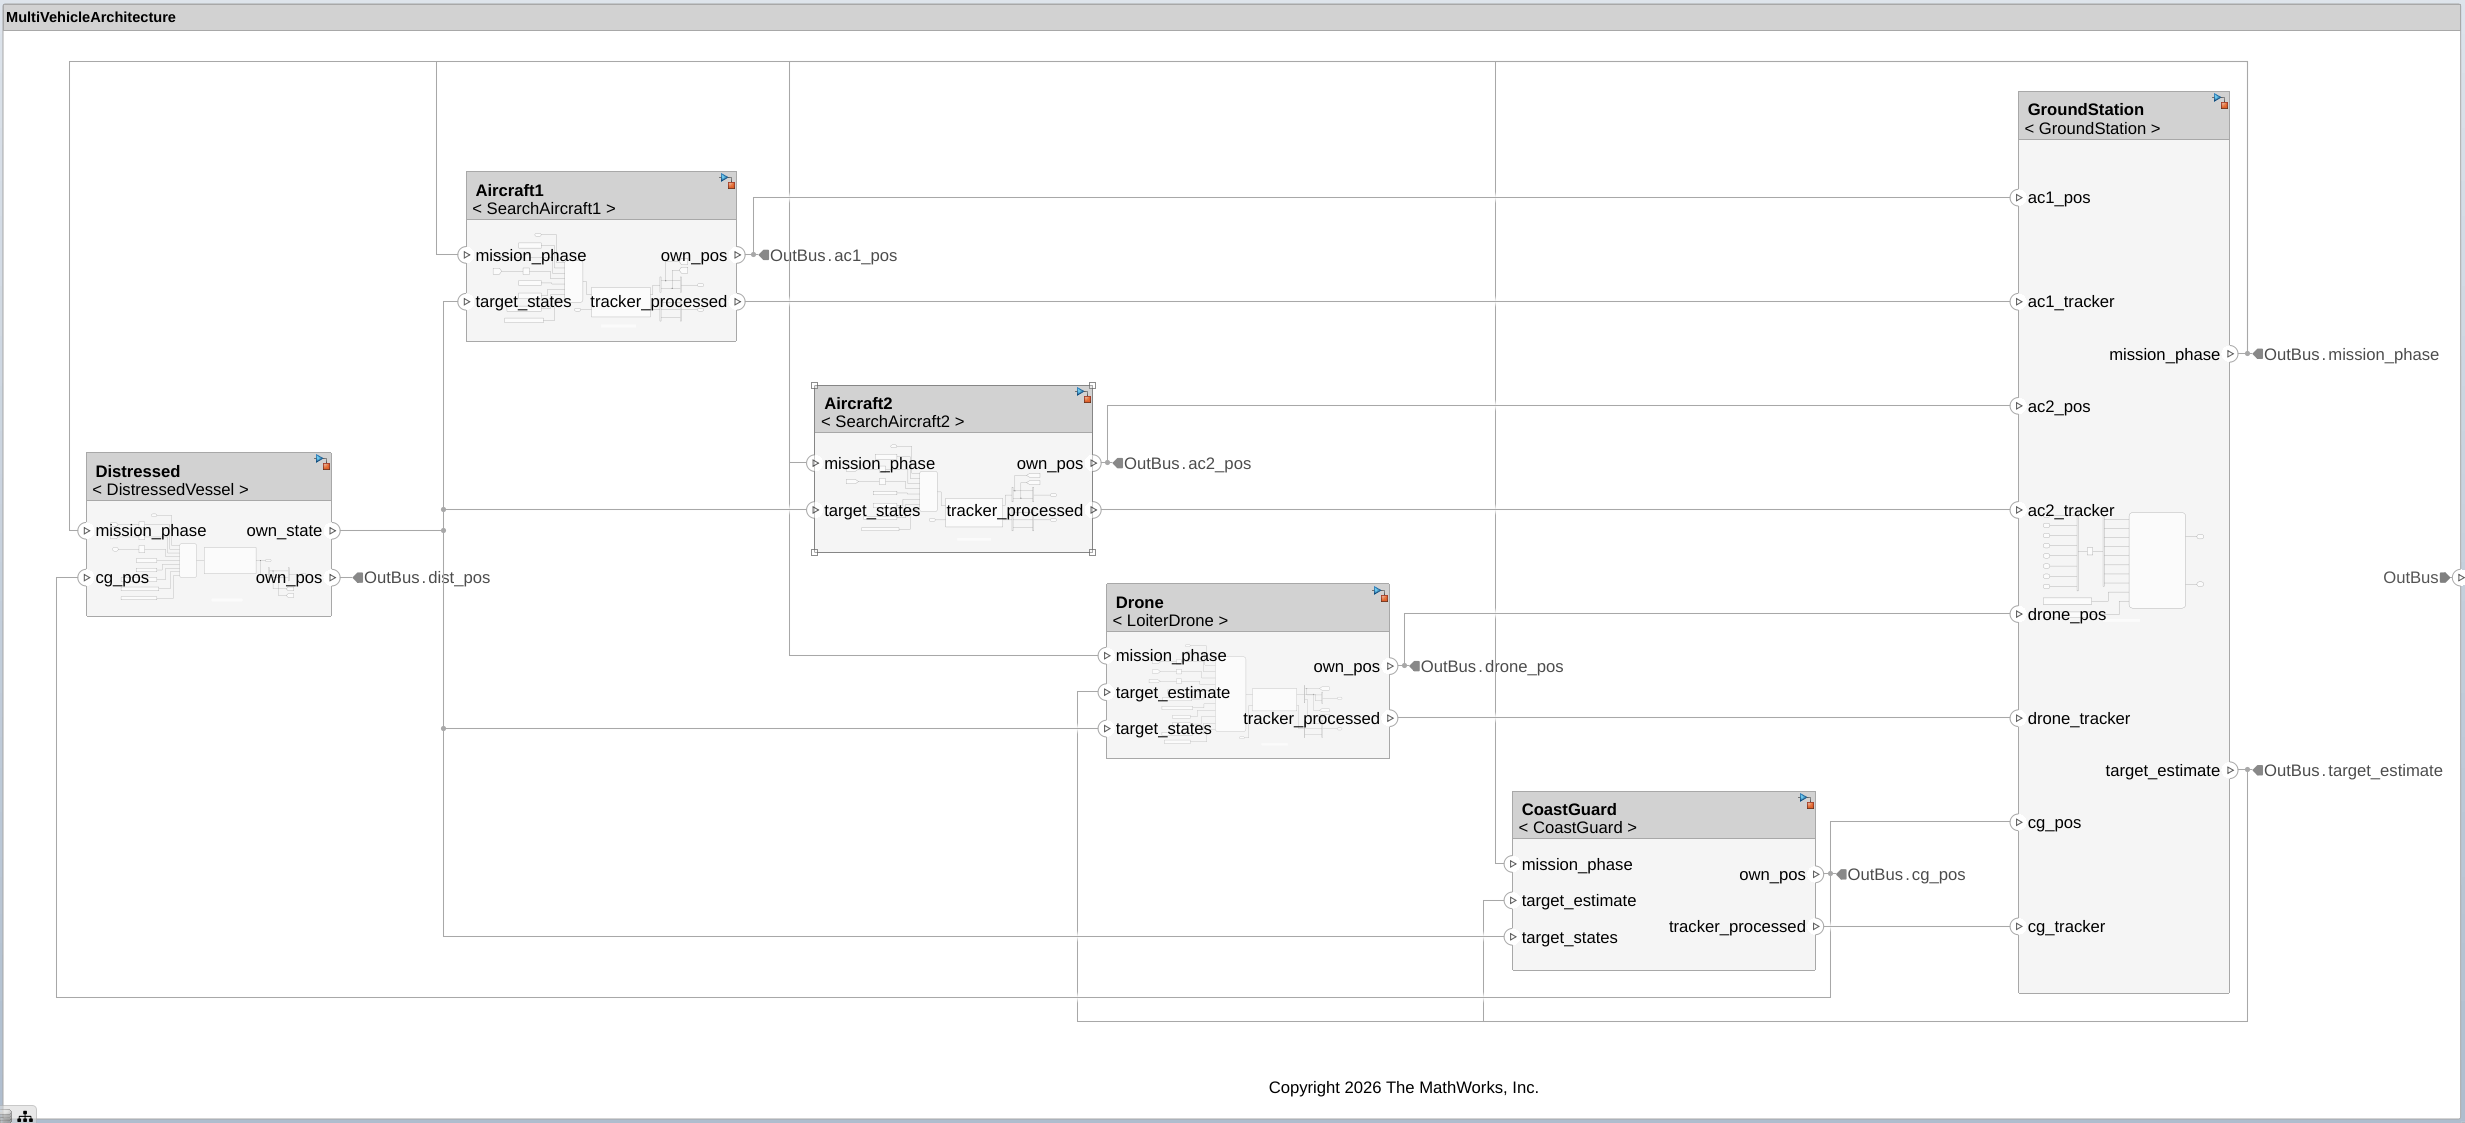
The architecture model MultiVehicleArchitecture.slx organizes six Model Reference components. Inter-vehicle communication flows through shared buses carrying mission phase and target estimates. Each component encapsulates a vehicle's dynamics, guidance law, and Stateflow® mission logic.
Requirements-Based Workflow
The example follows the V-model lifecycle with full traceability:
Stage | Artifact |
Requirements Capture | EARS-pattern requirements in a multi-tier hierarchy |
Architecture Design | 6-component Model Reference composition with shared buses |
Behavioral Design | Activity diagram (phase flow) and behavior allocation set |
Vehicle Modeling | Kinematic Aerospace Actor + Stateflow state machines + Aero.trajectory |
Simulation | Single-run interactive + parametric batch (stratified random sampling) |
Verification | Deterministic tests (VC/VB) + statistical batch tests (SOS/INT) |
Traceability | Derive + Implement + Verify links for full bidirectional coverage |
Requirements
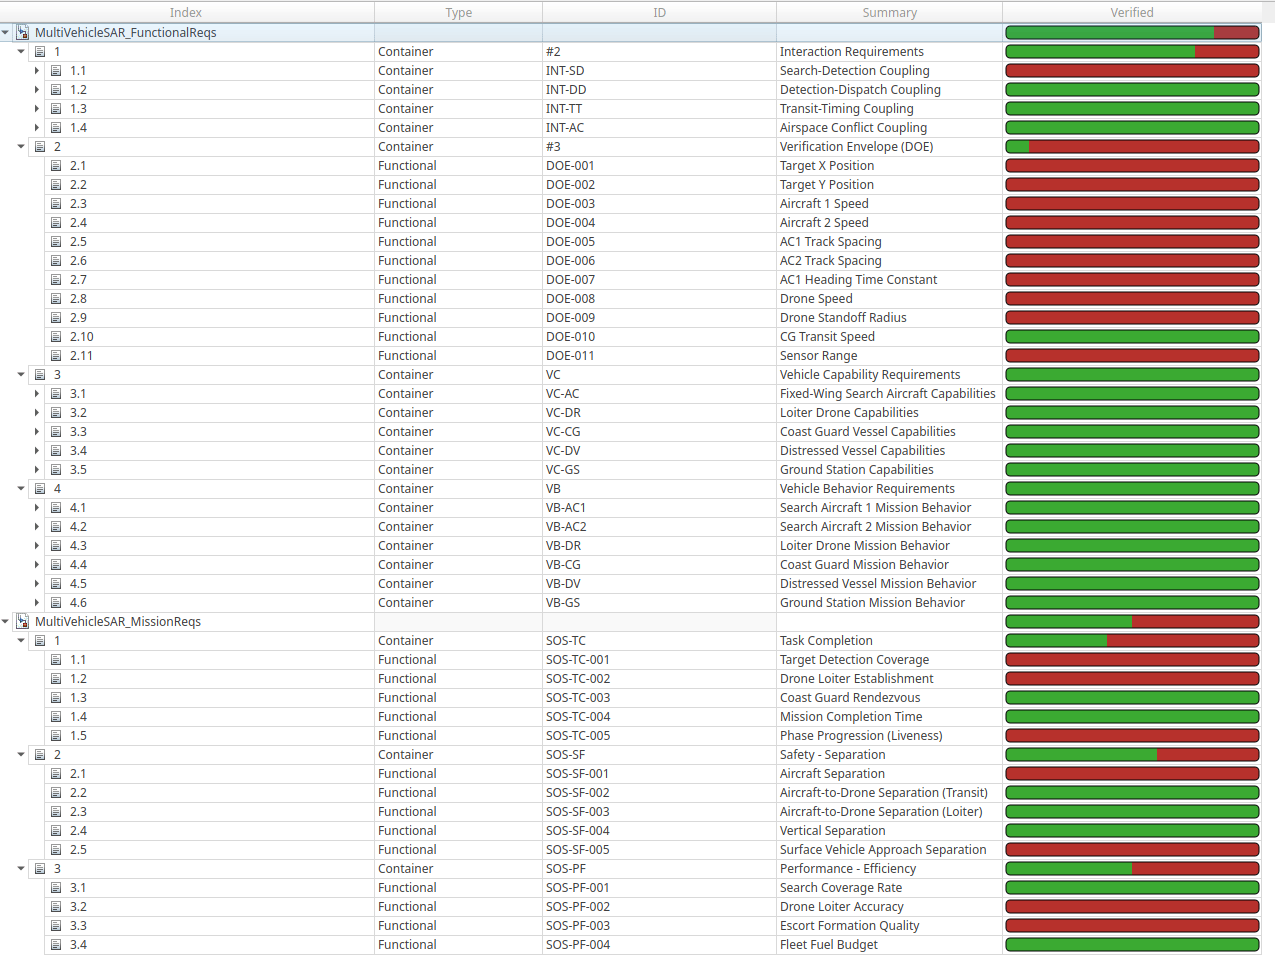
Requirements are structured in a tiered hierarchy using EARS (Easy Approach to Requirements Syntax) patterns:
Mission requirements (SOS-*) — System-of-systems goals: detect target within 800 s, maintain 200 m aircraft separation, achieve 50,000 m²/s coverage rate. These are emergent and require batch simulation.
Vehicle capabilities (VC-*) — What each vehicle can do in isolation: cruise speed, sensor range, endurance. Verified by single deterministic tests.
Vehicle behaviors (VB-*) — How each vehicle responds to mission events: phase transitions, guidance activation. Verified by single deterministic tests.
Interactions (INT-*) — Coupling between vehicles: detection-to-dispatch timing, transit sequencing, airspace deconfliction. Verified by parametric batch tests.
Traceability
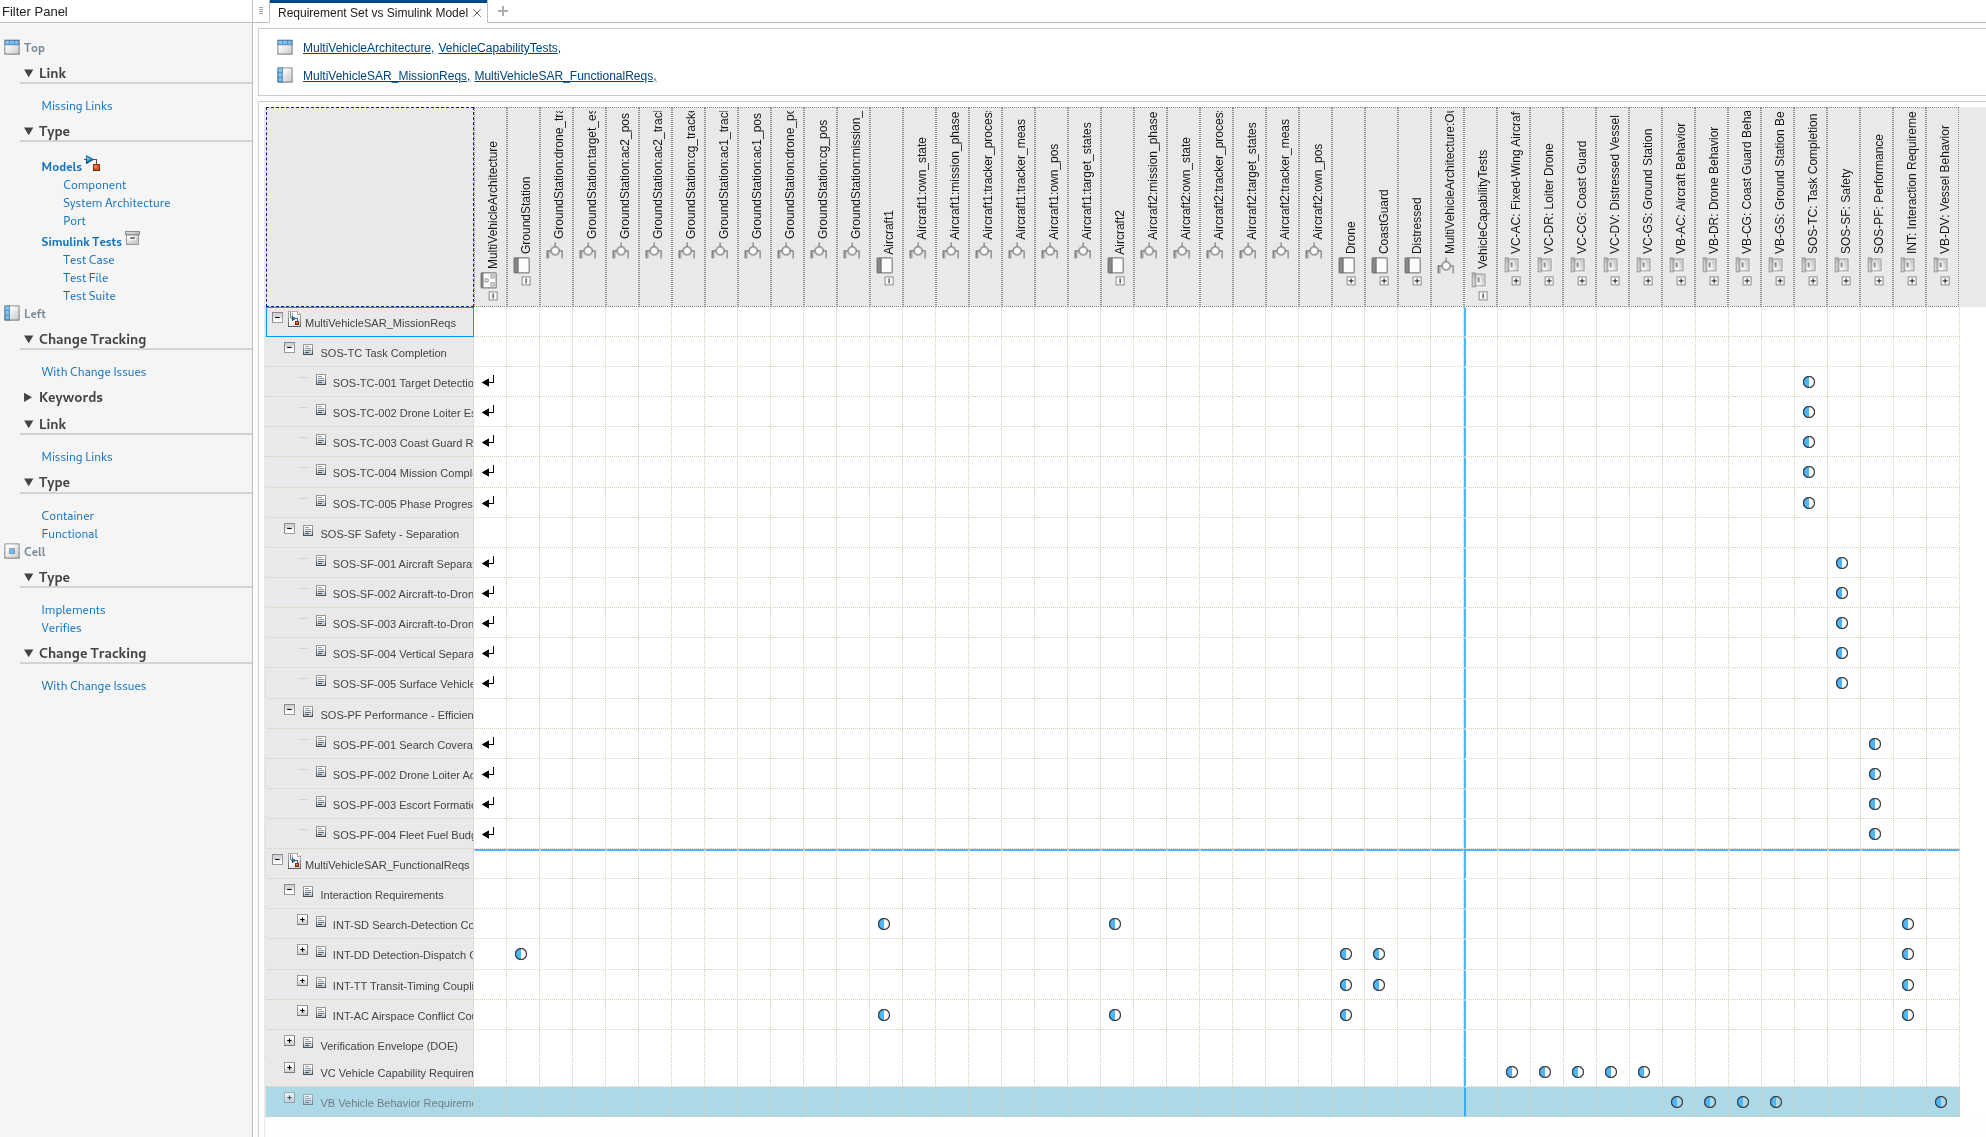
Full bidirectional traceability connects every requirement to its implementation and verification:
Derive links decompose mission requirements into vehicle-level functional specs
Implement links connect Simulink blocks and Stateflow charts to the requirements they satisfy
Verify links connect each requirement to its test case in Simulink Test Manager
Vehicle Models
Each vehicle is an independent Simulink model using a Kinematic Aerospace Actor block and Mission Planning APIs from Aerospace Blockset™, with a Stateflow chart for phase-dependent guidance. The Actor block encapsulates speed/heading/Flight Path Angle (FPA) response, sensor detection, and state output — all via dialog parameters, no custom dynamics code.
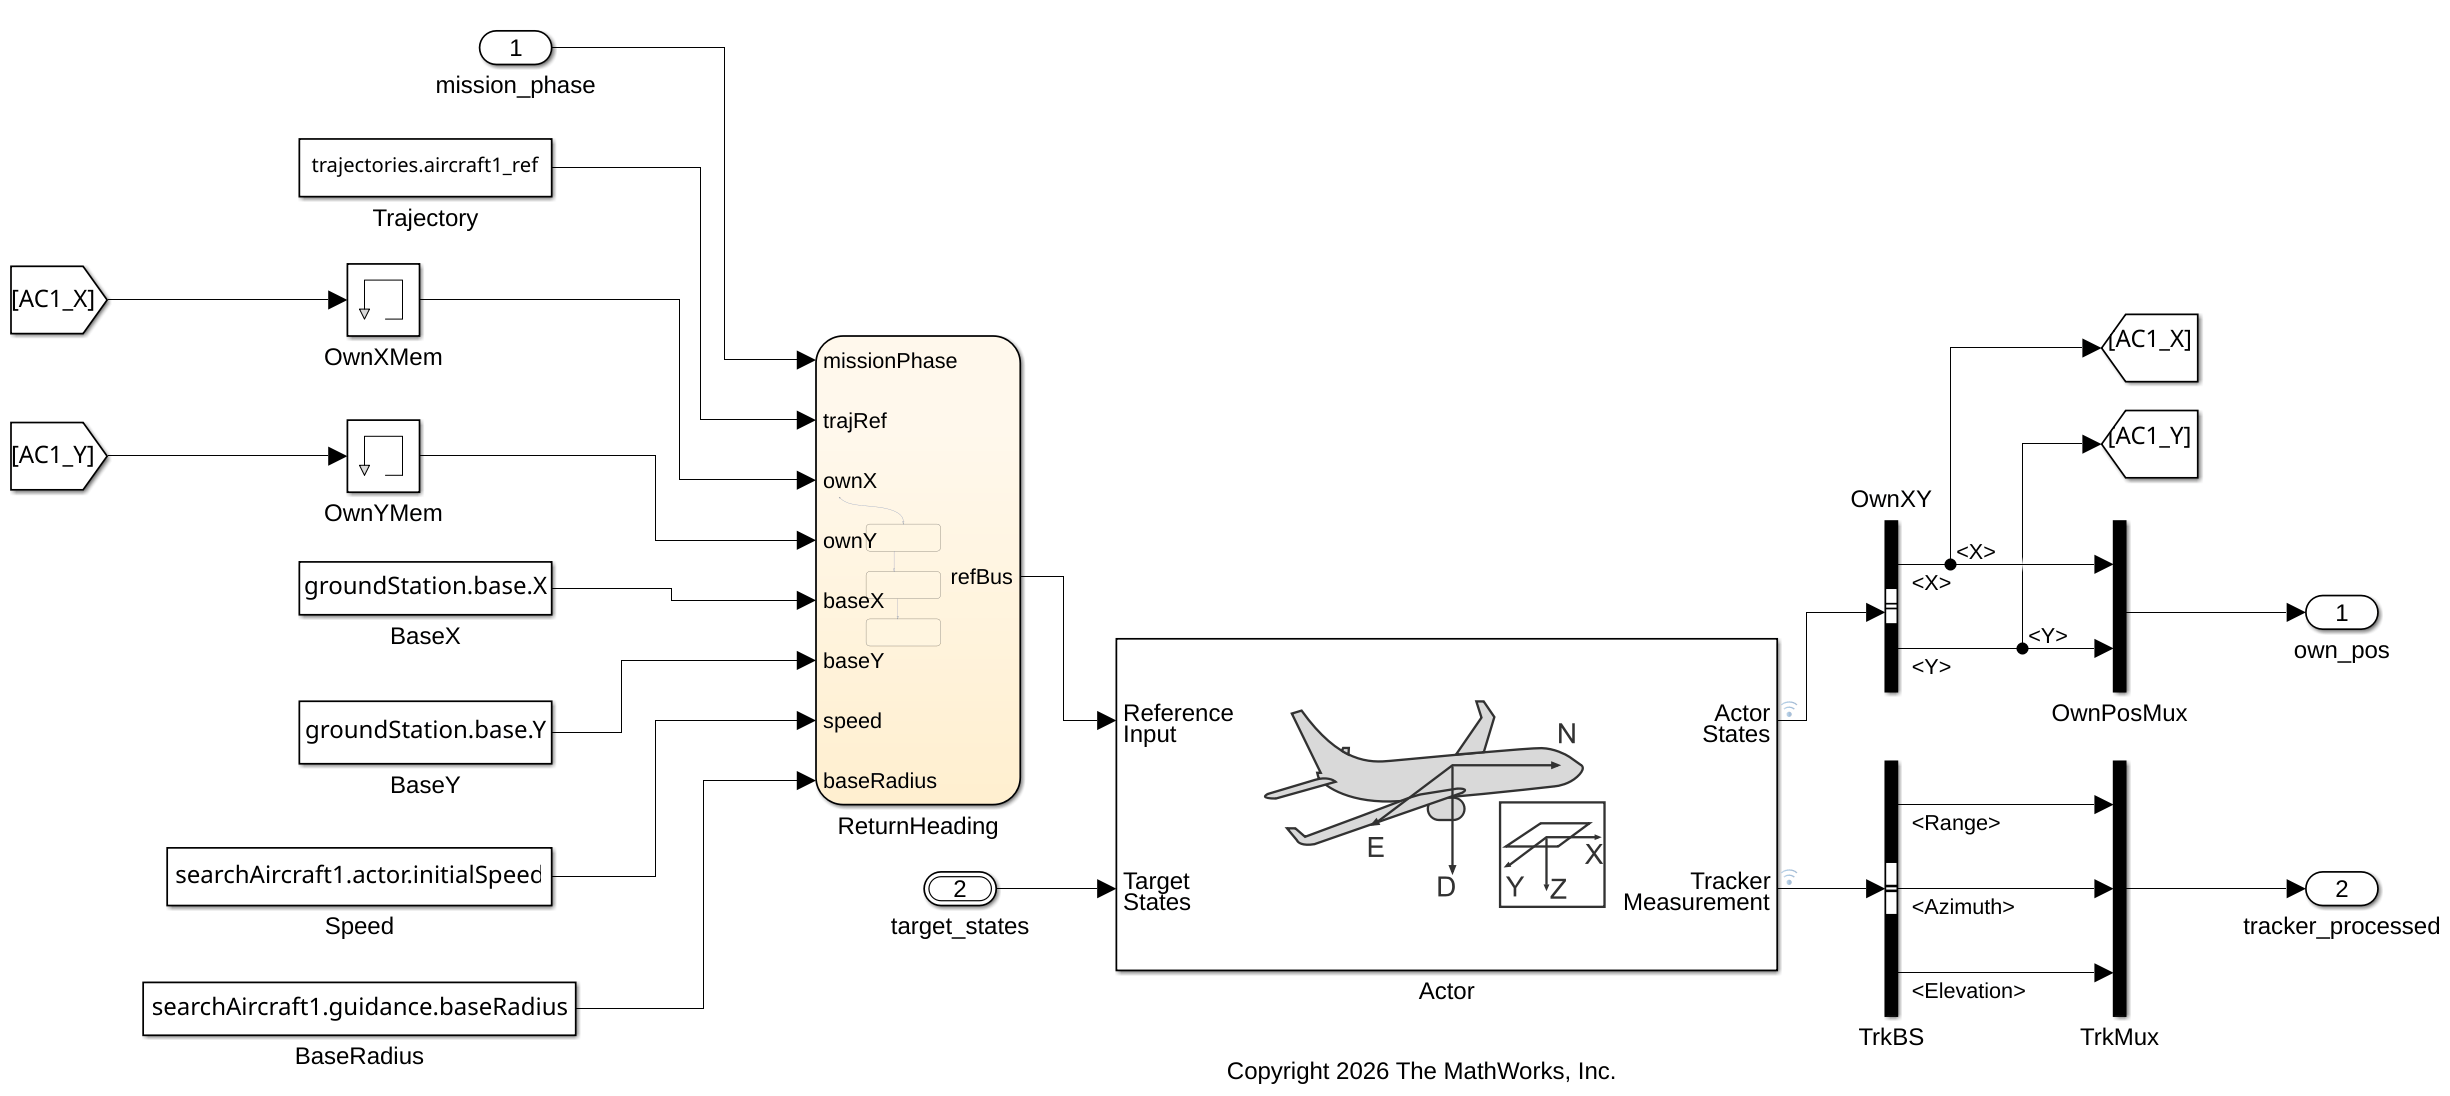
Search Aircraft 1 — Expanding square trajectory fed to Kinematic Aerospace Actor, with Stateflow chart for search/return phase switching and built-in tracker for target detection.
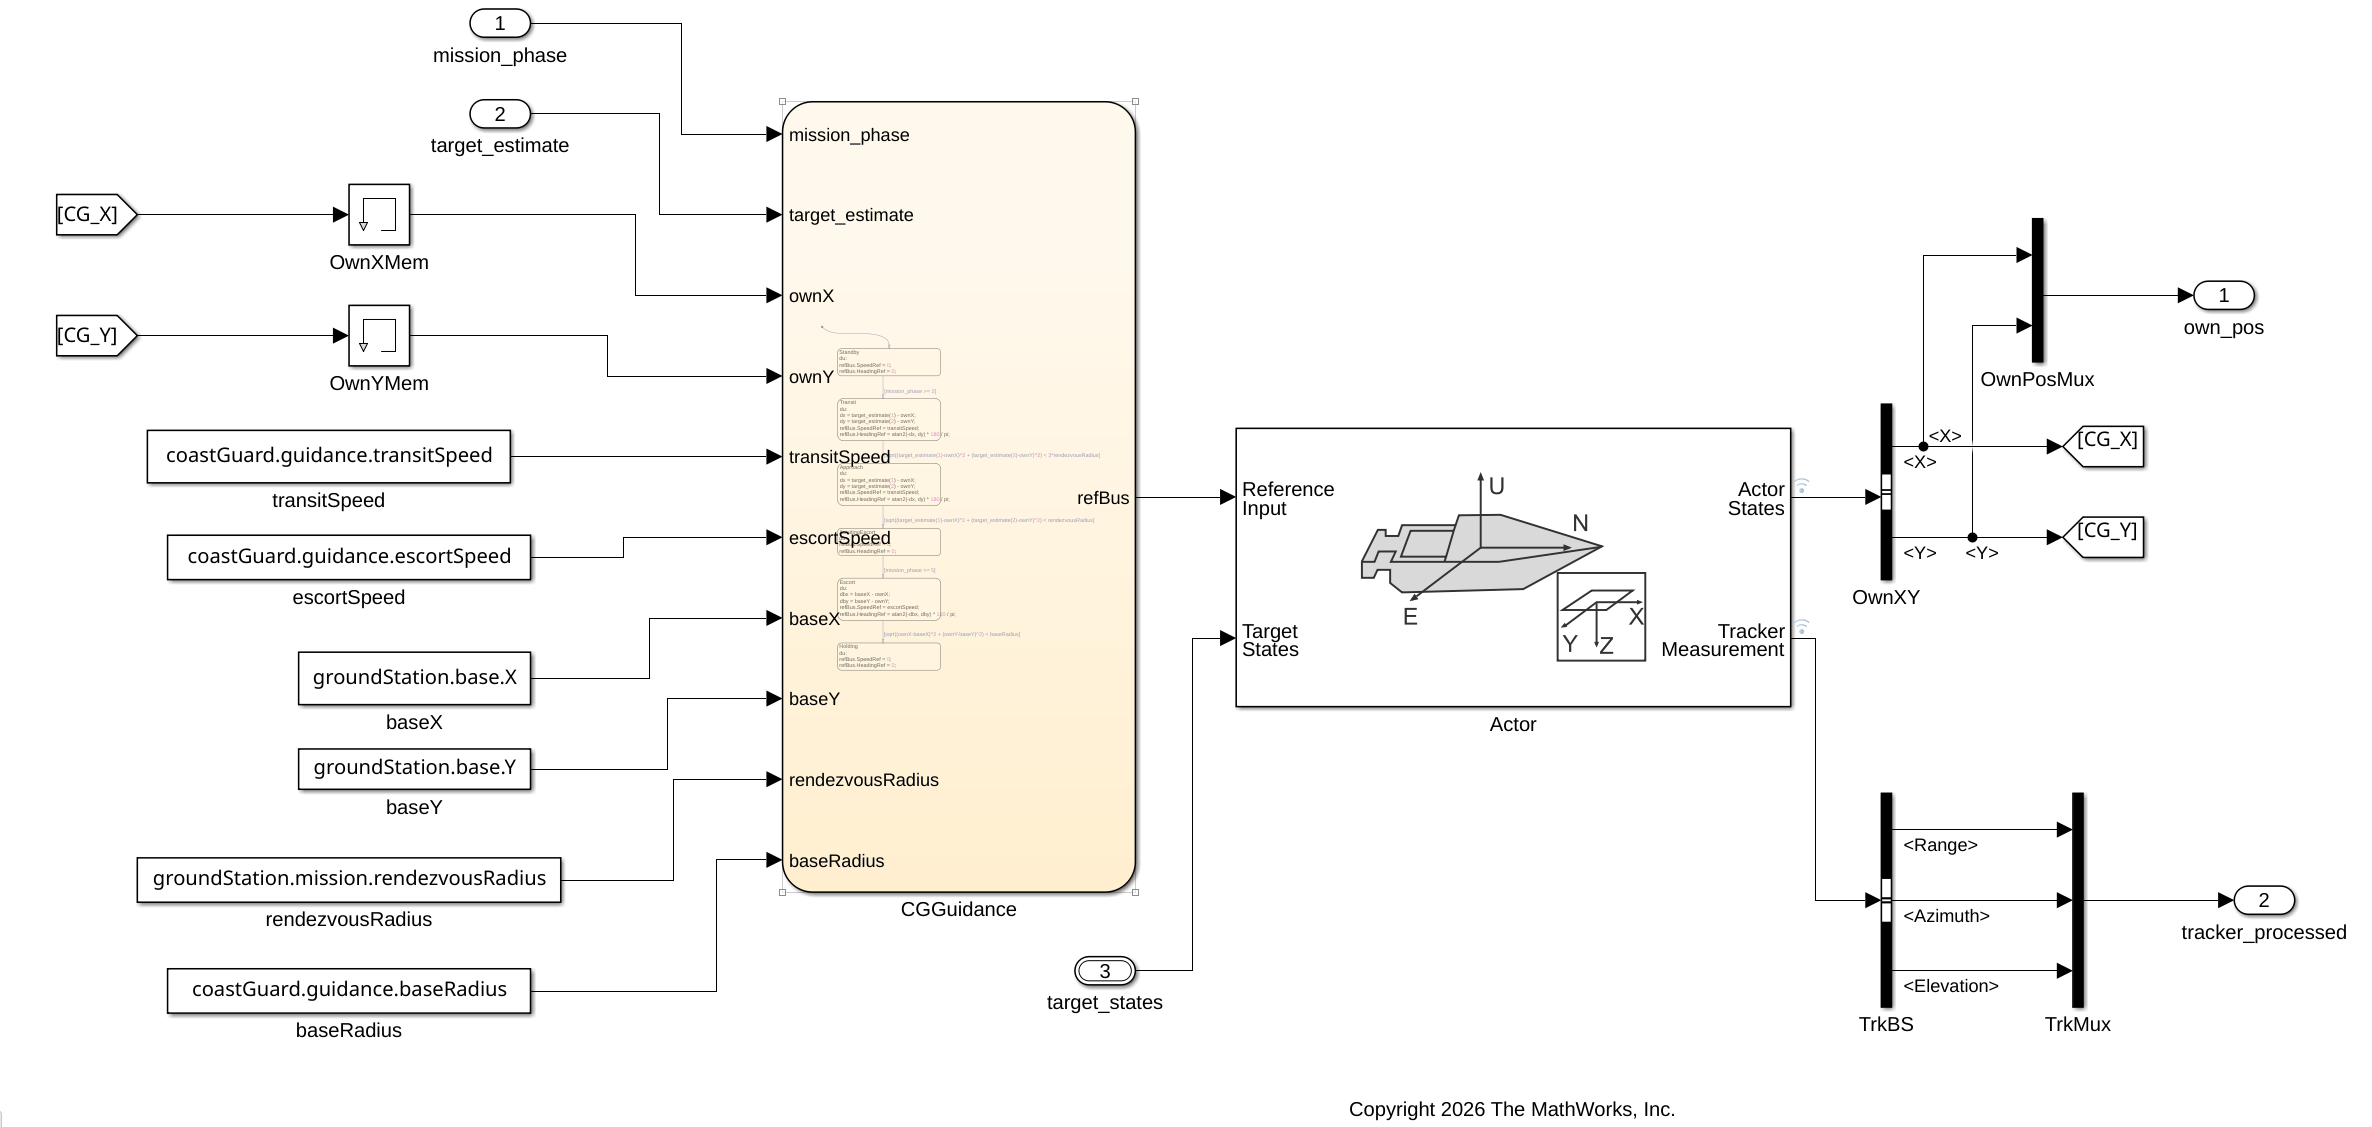
Coast Guard — Surface vessel with Stateflow guidance (Standby → Transit → Approach → Escort → Holding) and Kinematic Aerospace Actor block configured for surface dynamics.
Simulation and Emergent Behavior Validation
Single simulations verify deterministic vehicle behaviors. However, mission-level requirements exhibit emergent behavior — system outcomes that arise from vehicle interactions and cannot be predicted from individual specs.
The example uses stratified random sampling to generate parametric scenarios across the operational envelope (sensor range, drone speed, target location, CG transit speed). Batch simulation exposes failure modes invisible to single-vehicle testing:
Systemic gaps — Requirements failing in all scenarios (e.g., no collision avoidance logic)
Envelope boundaries — Requirements failing in some scenarios (e.g., slow drone + distant target exceeds time budget)
The "Closing the Loop" section demonstrates full traceability-driven debugging: failing test → requirement → implementation → fix → re-verify.
Verification Results
The project includes test suites in Simulink Test Manager covering all requirement tiers:
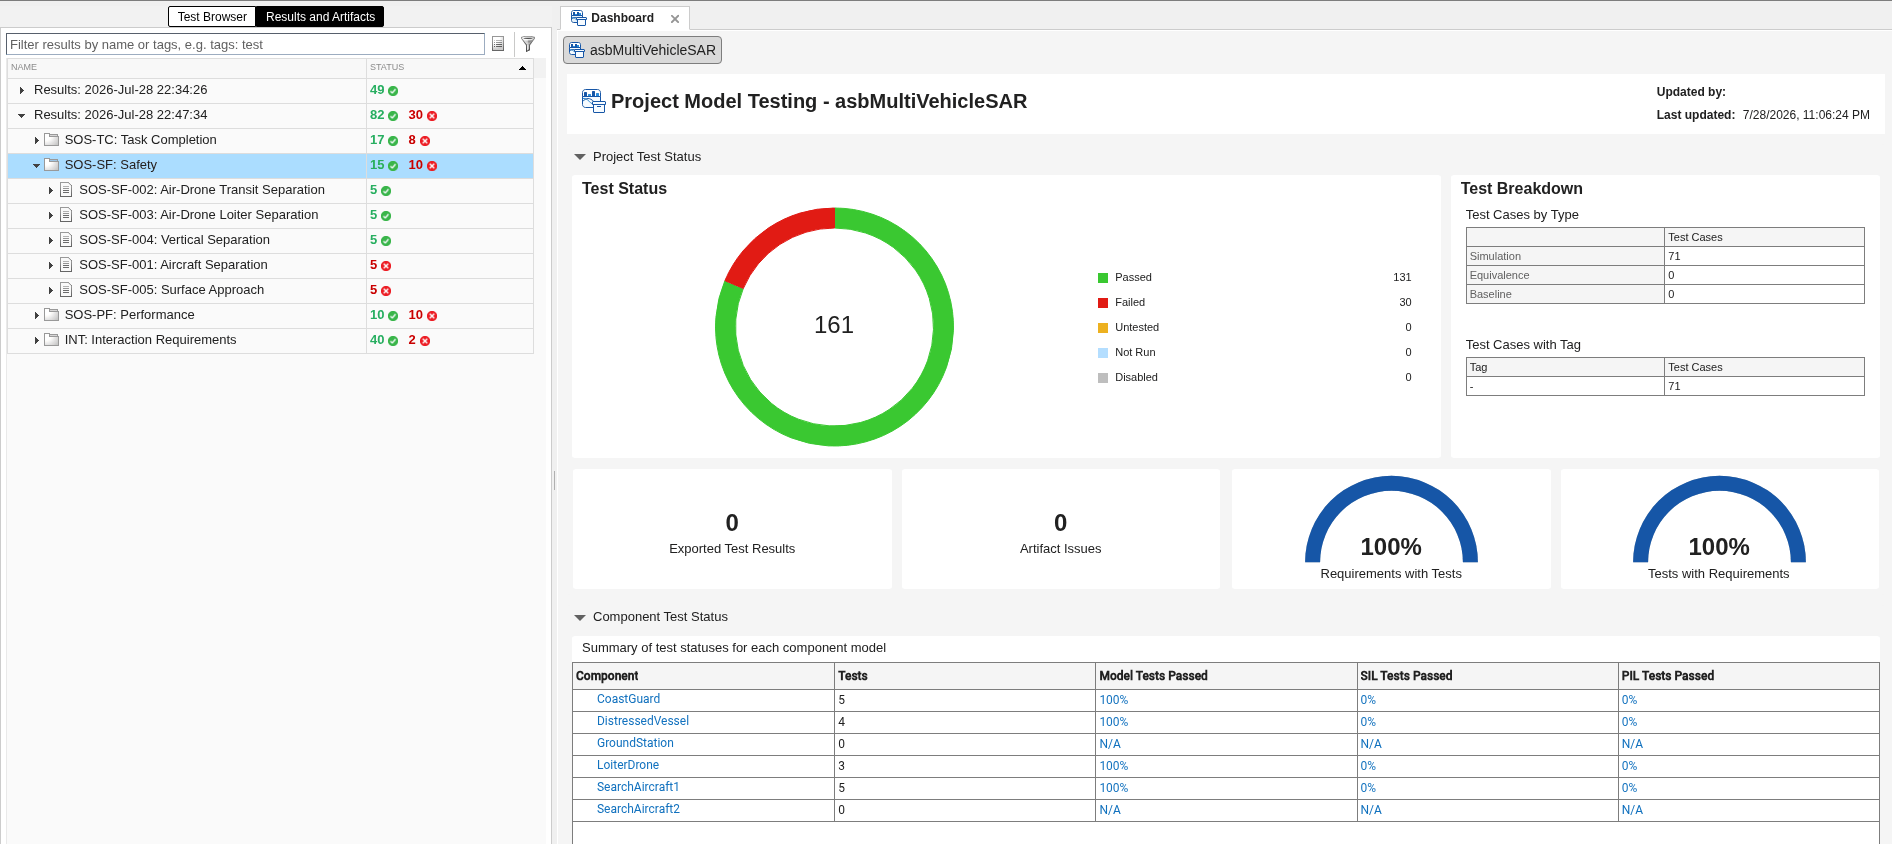
Vehicle capability tests (VC-*) — cruise speed, sensor range, turn rate saturation, detection limits. All pass.
Vehicle behavior tests (VB-*) — phase transitions, guidance response, trajectory tracking. All pass.
Interaction tests (INT-*) — detection-dispatch coupling, transit timing, airspace deconfliction. Near-clean with failures only in extreme parameter combinations.
Mission tests (SOS-*) — batch statistical assessment with pass-rate thresholds. Failures identify systemic design gaps and envelope boundaries.
Dashboard: 100% Requirements with Tests, 100% Tests with Requirements.
Explore the Project
After opening the project, run the RequirementBasedModelingAndVerification Live Script section by section for an interactive guided tour.
Understand the System
Mission phase flow (Search → Detect → Loiter → Approach → Rendezvous → Escort)
EARS-pattern requirements across multiple tiers with Derive/Implement/Verify link counts
System Composer architecture with 6 Model Reference components and shared-bus communication
Vehicle model detail: Kinematic Aerospace Actor configuration, Stateflow state machines, Aero.trajectory search patterns
Simulate and Explore
Configure target position in the data dictionary, generate trajectories, and run a single mission
Interactive phase plots (Timeline, Search, Detection, Escort) and animation
DesignStudy parameter sweep comparing heading controller dynamics (tau, turn rate limit)
Verify Requirements
Dual verification strategy: deterministic single-sim tests (VC/VB) + statistical batch tests (SOS/INT)
Test Manager integration: test cases with custom criteria and edge-case iterations for SOS/INT
Scripted batch execution with
runBatchSweepand assessment functions (assessTaskCompletion,assessSafety,assessPerformance)Results interpretation: systemic gaps vs. envelope boundaries
Close the Loop
Full traceability-driven debugging walkthrough: SOS-SF-001 fails → trace Verify link to requirement → follow Implement link to model element → fix
searchAircraft2.actor.initialXYin data dictionary → re-verify 0% → 100% pass

