Inverse Decoupled Transform (Six-Phase, Dual-Star)
R2026bImplement dqz1z2o1o2 to abc and xyz transform with variable angular displacement
Renamed from Inverse Decoupled Transform (Six-Phase) in R2026b
Inverse Decoupled Transform (Six-Phase, Dual-Star) block
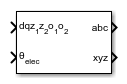
To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Simscape /
Electrical /
Control /
Mathematical Transforms
Description
The Inverse Decoupled Transform (Six-Phase, Dual-Star) block converts the
direct, quadrature, z1,
z2,
o1, and
o2 components in a rotating reference
frame to the components of a six-phase system in the abc and
xyz reference frame. The three-phase systems
abc and xyz are spatially shifted by
β electrical degrees.
You can configure the block to align the phase a-axis of the six-phase system to either the d-axis or q-axis of the rotating reference frame at time t equal to 0.
θ = ωt + Offset is the angle between the a and q axes for the q-axis alignment or the angle between the a and d axes for the d-axis alignment, where:
ω is the rotational speed of the rotational reference frame.
t is the time, in s, from the initial alignment.
Equations
The Inverse Decoupled Transform (Six-Phase, Dual-Star) block implements the transform as
The z1–z2 and o1–o2 pairs do not form a rotating magnetic potential. They are generalized zero-sequence components.
Ports
Input
Output
Parameters
References
[1] Amy, John. "Six Phase Synchronous Machine Model in Machine Variables and “Dq” Variables". 2019 IEEE Electric Ship Technologies Symposium (ESTS), Washington, DC, USA, 2019, pp. 421-429. DOI.org (Crossref), https://doi.org/10.1109/ESTS.2019.8847819.

