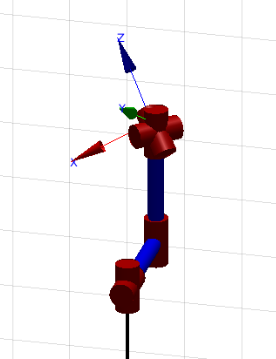
Open_Robo_Simulator
An Open Source Project for Kinematic Simulation of 6_DoF Serial Robotic Manipulator Arm.

引用格式
Ghanshyam Chandra (2026). Open_Robo_Simulator (https://github.com/gsc74/Open_Robo_Simulator), GitHub. 检索时间: .

要查看或报告此来自 GitHub 的附加功能中的问题,请访问其 GitHub 存储库。
要查看或报告此来自 GitHub 的附加功能中的问题,请访问其 GitHub 存储库。

