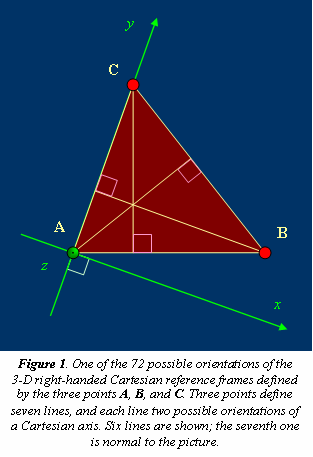
Defining Cartesian Reference Frames based on Point Positions
Defining 3-D Cartesian reference frames based on the positions of at least 3 non-collinear points
引用格式
Paolo de Leva (2026). Defining Cartesian Reference Frames based on Point Positions (https://ww2.mathworks.cn/matlabcentral/fileexchange/8787-defining-cartesian-reference-frames-based-on-point-positions), MATLAB Central File Exchange. 检索时间: .

