Virtual reality drawing with android device
use your android mobile phone to draw in 3D space like using virtual reality sets
- 214.0 次(全部时间)
- 1.0 次(过去 30 天)
- 5.0 / 5
- 社区
-
2017/5/27
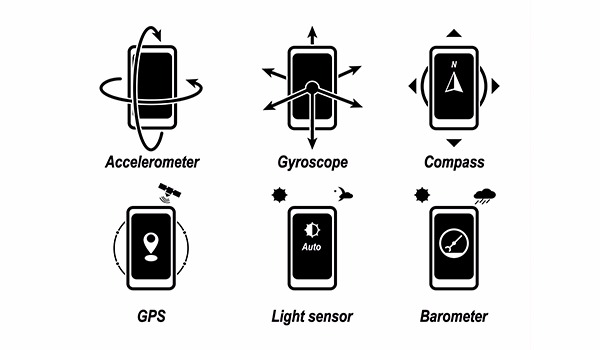
Attitude and Horizon Reference System (AHRS) application using Onboard smartphone Sensors (Android for Demo)
Attitude and Horizon Reference System (AHRS) application using Onboard smartphone Sensors Linear Kalman Filter and Complementary Filter Attitude Estimation (AHRS) Using Onboard Smart Phone IMUUsing
- 386.0 次(全部时间)
- 2.0 次(过去 30 天)
- 5.0 / 5
- 社区
-
2020/5/22
AHRS algorithm based on kalman filter for smartphone attitude determination.
# AHRS_KFAHRS algorithm based on kalman filter for attitude determination.simulating "CONCEPT OF AHRS ALGORITHM DESIGNED FOR PLATFORM INDEPENDENT IMU ATTITUDE ALIGNMENT" Article in matlab# Simulink
- 25.0 次(全部时间)
- 2.0 次(过去 30 天)
- -- / 5
- 社区
-
2024/9/2

Real time EKF Attitude Estimation for Simulink
rad/sMagnetometer data should be utdt (time step) can be either a fixed step time or variable (in seconds)Outputs:Euler Angles Roll, Pitch, Heading (Yaw) in Radians*** Remember to add the path to AHRS-master folders
- 667.0 次(全部时间)
- 3.0 次(过去 30 天)
- -- / 5
- 社区
-
2020/11/20
orientation_estimation_sensor_fusion_algorithm_codes
MATLAB implementations of 10 sensor fusion algorithms for orientation estimation using magneto-inertial measurement units (MIMU).
- 311.0 次(全部时间)
- 2.0 次(过去 30 天)
- -- / 5
- 社区
-
2021/6/10
Device Drivers for the BeagleBone Black
Development of Simulink Device Driver Blocks for the BeagleBone Black
- 3.2K 次(全部时间)
- 16.0 次(过去 30 天)
- 5.0 / 5
- 社区
-
2015/2/13

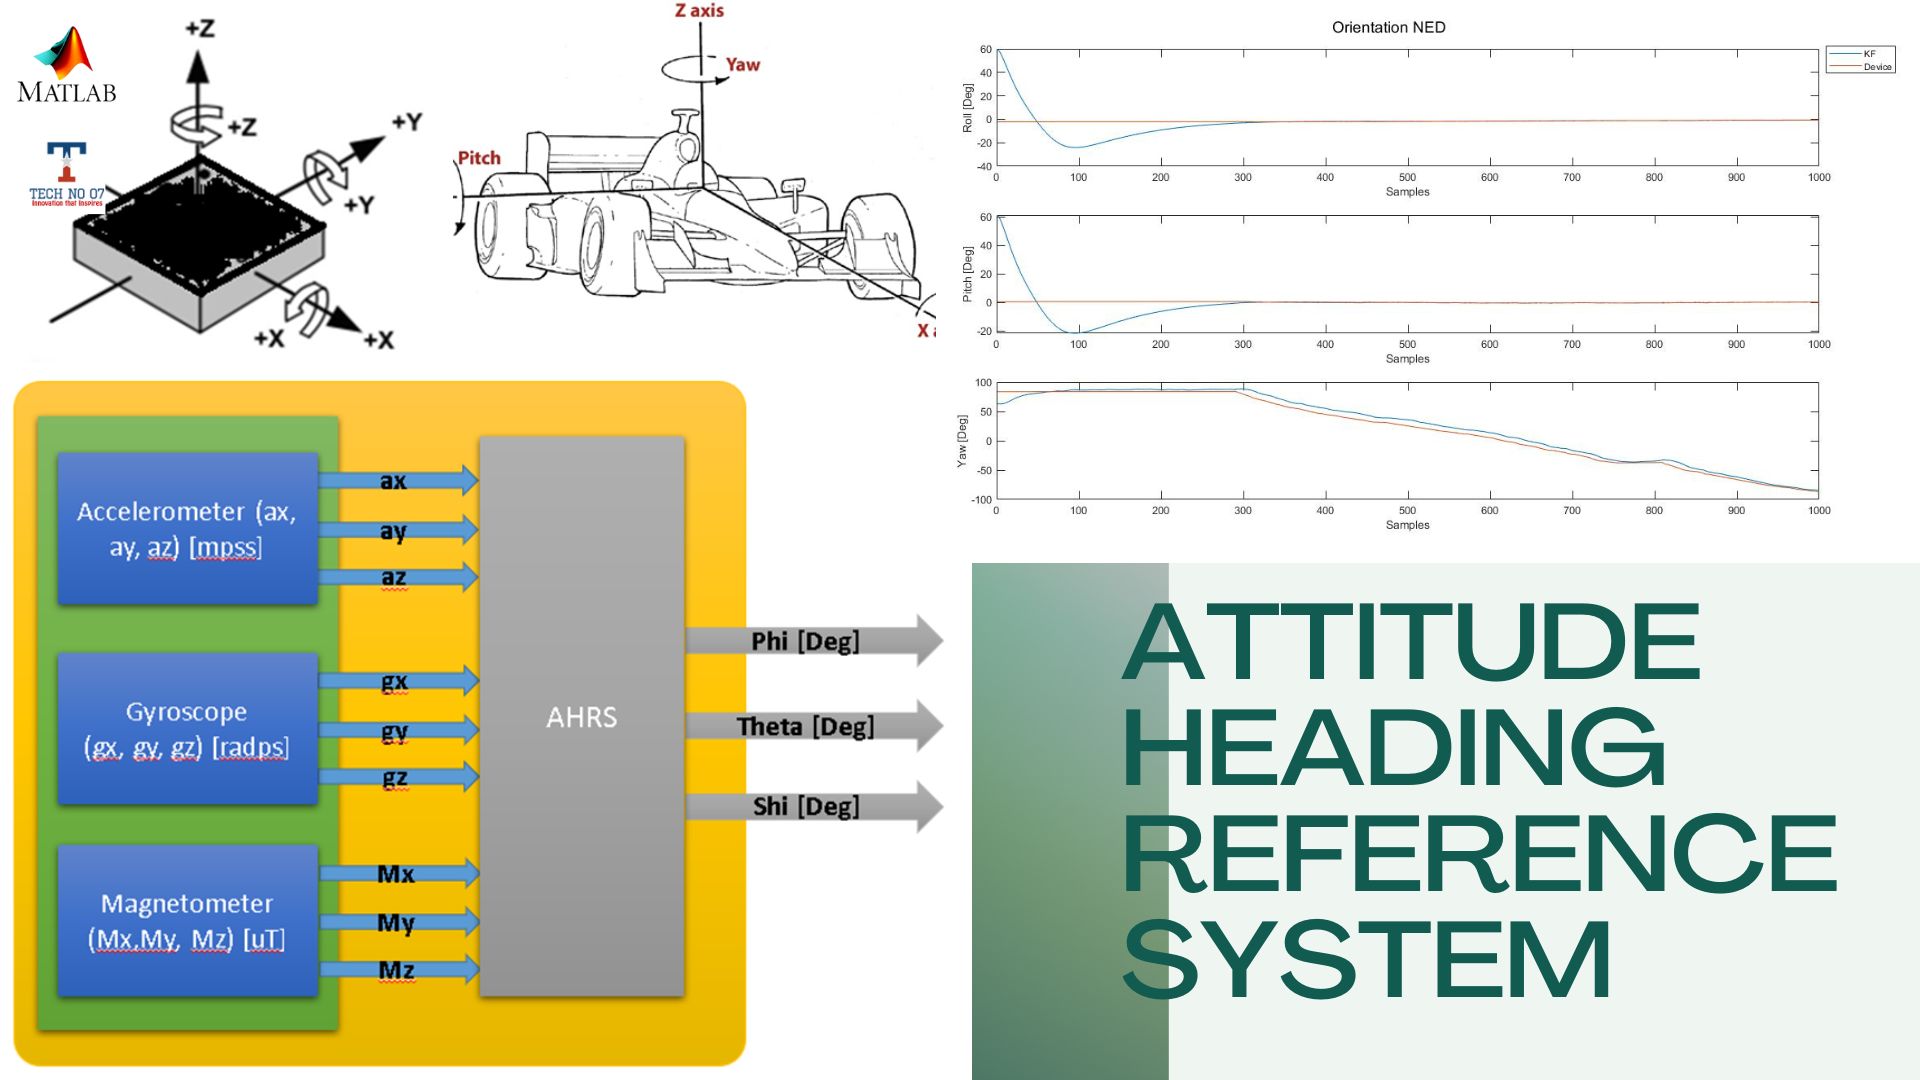
Attitude Heading Reference System using Kalman Filter
In this project, I have developed an AHRS with Linear Kalman Filter. A clear documentation on how I built it is given as a blog.
- 234.0 次(全部时间)
- 3.0 次(过去 30 天)
- 4.5 / 5
- 社区
-
2022/8/14
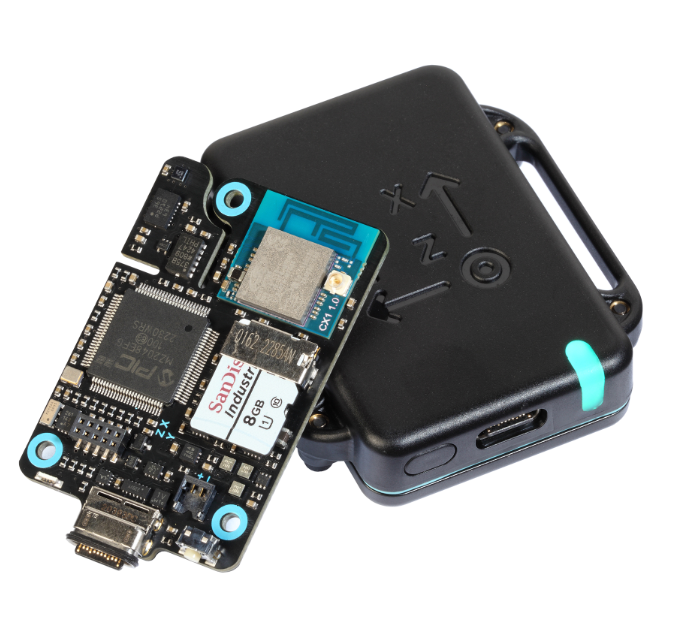
xIMU3 toolbox: A dedicated toolbox to stream quaternions, euler, acceleration and gyro outputs in real time with required rate (max- 400Hz).
accelerometer- Configurable AHRS/inertial streaming rates- SLIP packet decoding and angle unwrapping## Quick Usage```matlab% Create IMU objectimu = xIMU3Mod('tcp', '192.168.1.1', 7000);% OR serial% imu =
- 17.0 次(全部时间)
- 2.0 次(过去 30 天)
- -- / 5
- 社区
-
2025/8/6
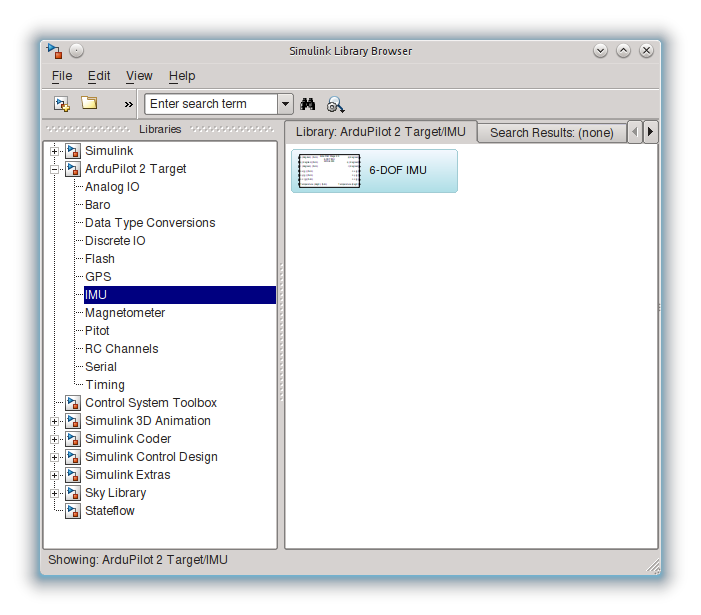
Simulink blockset for use with the ArduPilot Mega 2.0 hardware. Includes blocks to read external rad
- 10.1K 次(全部时间)
- 19.0 次(过去 30 天)
- 4.6 / 5
- 社区
-
2012/11/13
MEMS Accelerometer Calibration using Gauss Newton Method
Computes the Scale factor Matrix and the bias vector of a MEMS accelerometer
- 3.2K 次(全部时间)
- 2.0 次(过去 30 天)
- 4.2 / 5
- 社区
-
2015/4/7
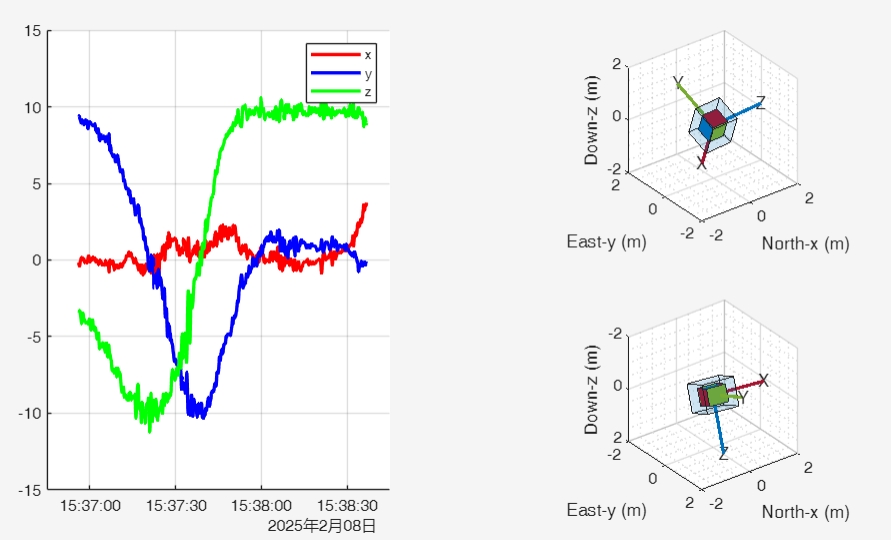
Uses a smartphone with a 6-axis sensor (3-axis accelerometer + 3-axis gyroscope) to calculate the smartphone's orientation angle
# 6DOF sensor fusion本仓库利用手机6轴(3轴加速度+3轴陀螺仪)来实时解算手机方位角!AHRS(Attitude and Heading Reference System)算法在MATLAB中实现非常广泛,参考了一些C/C++和MATLAB开源代码[^1],[^2]。## Notes1. [Balance-Teapot/](./Balance-Teapot
- 45.0 次(全部时间)
- 1.0 次(过去 30 天)
- -- / 5
- 社区
-
2025/2/8
Real-time attitude estimation algorithm series using Rust firmware on Raspberry Pi Pico H and BNO05
UART at 100 Hz to a PC, where MATLAB tools handle calibration, logging, and attitude estimation.The goal is to implement every attitude estimation algorithm from the AHRS library in MATLAB from scratch
- 7.0 次(全部时间)
- 1.0 次(过去 30 天)
- -- / 5
- 社区
-
2026/5/18
Marine Systems Simulator (MSS)
MATLAB and GNU Octave library for modeling, simulation and control of ships, offshore structures, USVs, AUVs and ROVs, plus MSS-Capytaine.
attitude observer with angular-rate sensor bias estimation.- Position-, velocity-, compass-, magnetometer-, AHRS-, and pressure-aided navigation examples, including heave estimation.- IMU test-signal
- 6.1K 次(全部时间)
- 106.0 次(过去 30 天)
- 4.6 / 5
- 社区
-
2026/10/20

Data Center Design with Simscape
Learn how to design modern data centers by specifying server rack layouts, power ratings for typical power system and HVAC analysis.
- 376.0 次(全部时间)
- 156.0 次(过去 30 天)
- -- / 5
- 社区
-
2026/6/25

- 4.3K 次(全部时间)
- 25.0 次(过去 30 天)
- 5.0 / 5
- 社区
-
2026/2/11

