主要内容

Point Cloud Registration Analyzer

R2026b

Compare, tune, and analyze point cloud registration results

Renamed from Lidar Registration Analyzer in R2026b

Description

The Point Cloud Registration Analyzer app enables you to interactively register point clouds and compare the results of using different registration techniques. The app enables you to interactively:

  • Register point clouds

  • Visualize the alignment of the point clouds

  • Apply point cloud preprocessing techniques to optimize the speed and accuracy of the registration

  • Tune registration and preprocessing parameters

  • Preview the effects of preprocessing point clouds before attempting registration by viewing the original and preprocessed point clouds.

To learn more about this app, see Get Started with the Point Cloud Registration Analyzer App.
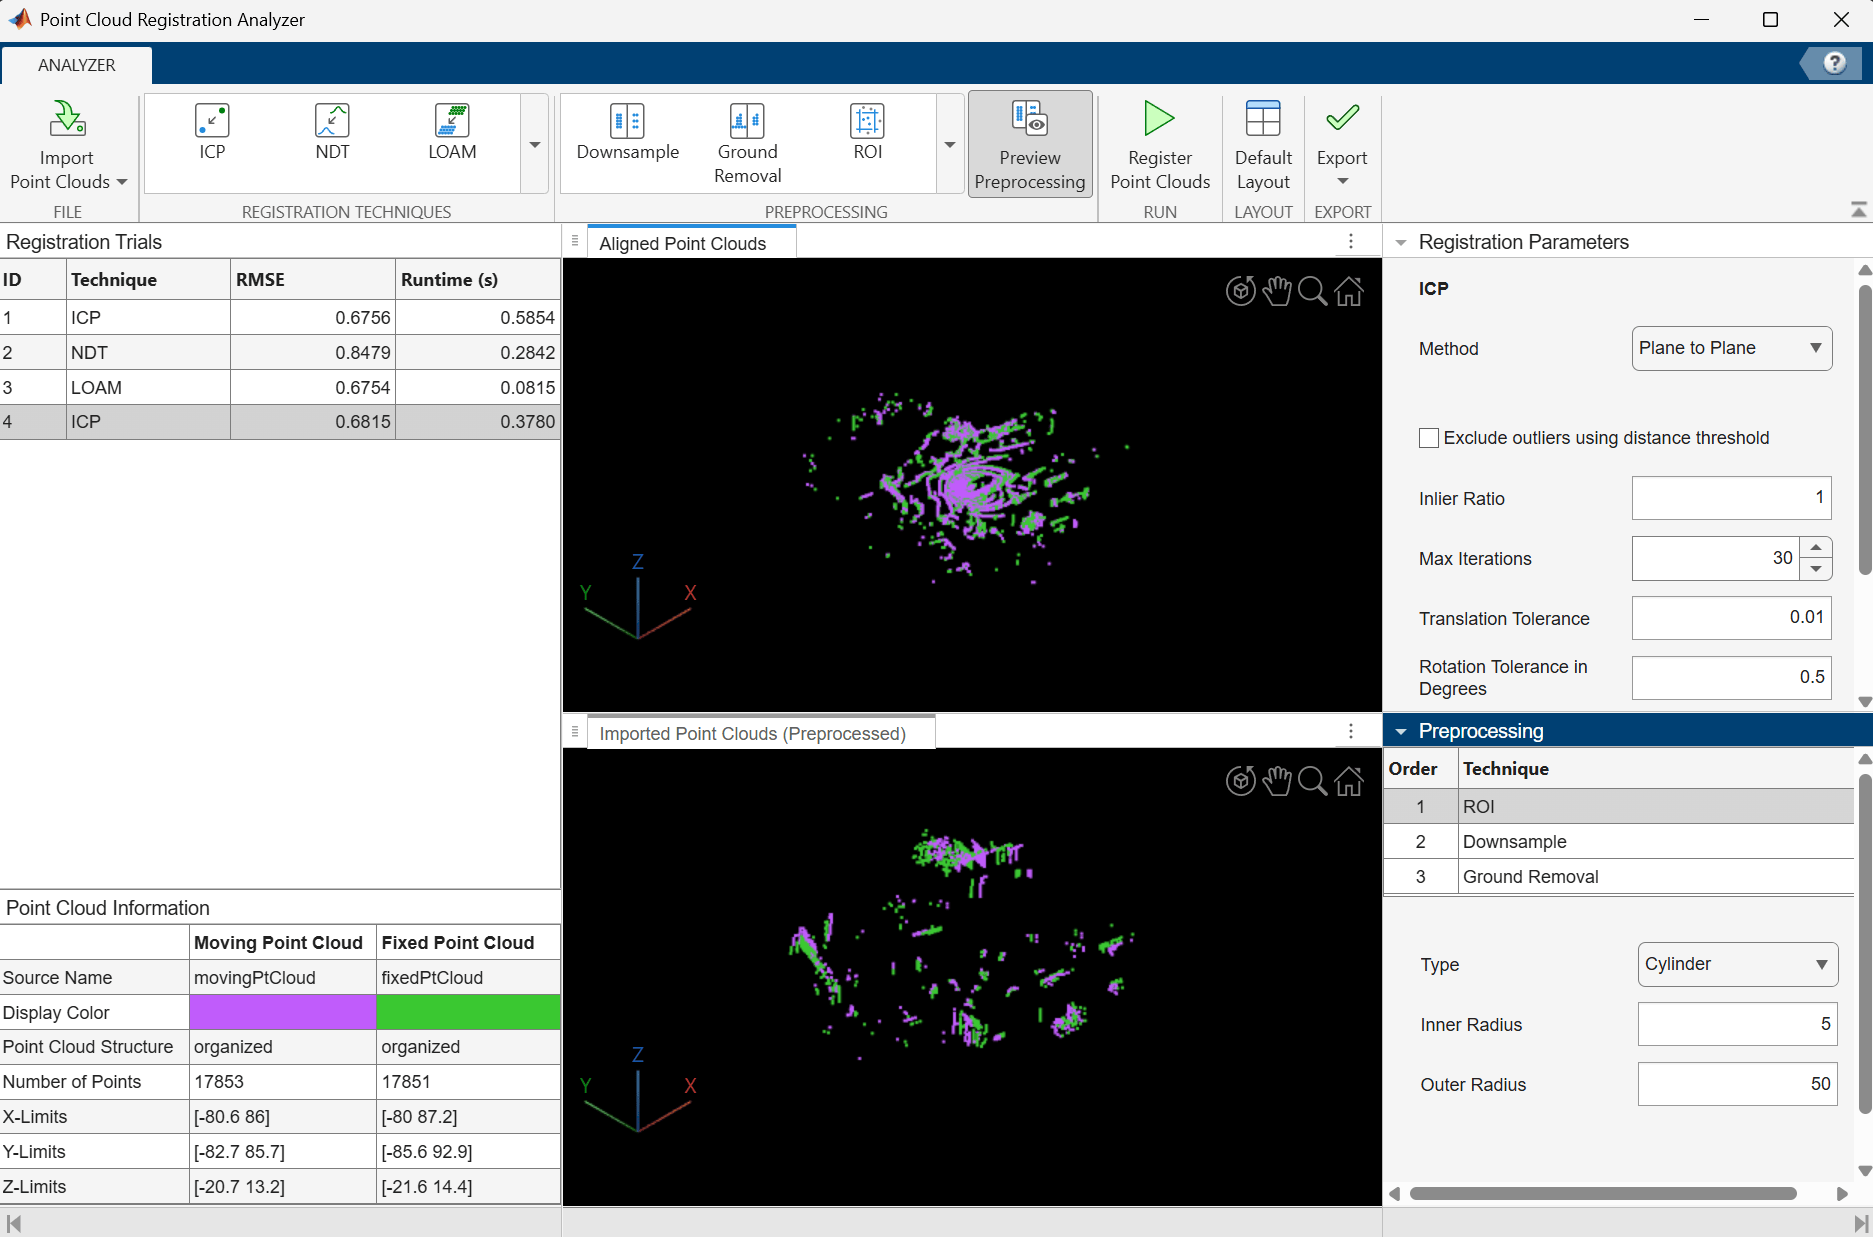
Point Cloud Registration Analyzer App

Open the Point Cloud Registration Analyzer App

  • MATLAB® Toolstrip: On the Apps tab, under Image Processing and Computer Vision, click the app icon, Point Cloud Registration Analyzer app icon.

  • MATLAB command prompt: Enter pointCloudRegistrationAnalyzer.

Examples

expand all

After running the command to launch the app, you can use its interface to load and register point clouds.

On the MATLAB command line, type:

pointCloudRegistrationAnalyzer

On the app toolstrip, select Import > From File. Choose a data source from the list.

Parameters

expand all

Import organized or unorganized point clouds, specified as either a PCD or PLY format file.

Registration techniques, specified as ICP, NDT, LOAM, FGR, Phase Correlation, or CPD. The Point Cloud Registration Analyzer app offers various registration techniques for aligning point clouds. These are the techniques you can choose from in the app.

  • Iterative Closest Point (ICP) — Iteratively aligns two point clouds by minimizing the point-to-point, point-to-plane, or plane-to-plane distance between the corresponding points of the point clouds.

  • Normal Distributions Transform (NDT) — Utilizes normal distributions in each voxel to find the transformation that best aligns the point clouds.

  • Lidar Odometry and Mapping (LOAM) — Feature-based approach to align two point clouds that detects and matches edge and surface points between the point clouds, and then minimizes the distance between the matched points.

  • Fast Global Registration (FGR) — Feature-based approach based on fast point feature histogram (FPFH) features.

  • Phase Correlation — Recommended for ground vehicles with a horizontally mounted lidar sensor moving on a flat surface in which you can describe the transformation as a translation in the X-Y plane and a rotation around the Z-axis.

    Note

    The Phase Correlation technique requires the Image Processing Toolbox™.

  • Coherent Point Drift (CPD) — Computationally intensive technique recommended for small point clouds, of roughly 10,000 points or less.

Preprocess point clouds, specified as Region of Interest (ROI), Downsample, and Ground Removal techniques. You can select any combination of preprocessing steps and interactively modify their parameters.

  • Region of Interest (ROI) — Select a region of interest to constrain registration to use points in the specified region. This can improve both speed and accuracy, especially if you know that an area of your point cloud contains a higher number of outliers or inliers than the rest of the point cloud. ROI is the least computationally intensive preprocessing step available. When including this step, consider adding it before the other preprocessing steps to improve the preprocessing speed for subsequent steps.

  • Downsample — Improves the accuracy and speed of registration by reducing the number of points to use for registration to a representative set of points. The app supports Voxel Filter, Random, Nonuniform Grid Sample downsampling methods.

  • Ground Removal — Removing the ground in a point cloud scene usually reduces registration time. For some scenes, ground removal can improve the accuracy of the registration, because the points containing the ground are similar throughout the point cloud. In other cases, the ground plane improves registration accuracy along the z-axis, so removing the ground is not always the best option. The app supports Simple Morphological Filter (SMRF) and Plane Fitting ground removal methods.

Register point cloud. Register the aligned moving point cloud and transformation.

Export point cloud registration results to the workspace. You can export any registered trial by selecting the trial in the Registration Trials pane, then select Export. You must register a trial before you can export it. You can export the aligned moving point cloud and transformation to the workspace, or export the registration trial to a MATLAB function.

Programmatic Use

pointCloudRegistrationAnalyzer opens a new session of the app, enabling you to register point clouds.

Tips

  • You do not need to include preprocessing steps to register point clouds. Registering point clouds before you apply preprocessing steps can give you a good initial evaluation. For more details about using preprocessing techniques, see Add Preprocessing Steps for Point Cloud Registration.

Algorithms

The Point Cloud Registration Analyzer app offers various registration techniques for aligning point clouds. This table summarizes these techniques.

TechniqueDescriptionIterativeSupports Unorganized Point CloudsRelies on Initial TransformationFeature-Based
Iterative closest point (ICP)Minimizes the point-to-point, point-to-plane, or plane-to-plane distance between the points to align the point clouds.✓✓✓X
Normal distributions transform (NDT)Uses normal distributions in each voxel to find the transformation that best aligns the point clouds.✓✓✓X
Lidar odometry and mapping (LOAM)Feature-based approach that detects and matches edge points and surface points between the two point clouds, then minimizes the distance between the matched points to align the point clouds.✓X✓✓
Fast global registration (FGR)Global registration method. Recommended when you do not have an initial transformation and the initial misalignment is significant. Based on fast point feature histogram (FPFH) features.✓✓X✓
Phase correlationRecommended for ground vehicles, with a horizontally mounted lidar sensor moving on a flat surface in which the transformation can be described by a translation in the X-Y plane and a rotation around the Z-axis.X✓XX
Coherent point drift (CPD)Computationally intensive technique recommended for small point clouds, of roughly 10,000 points or less, or for larger point clouds with significant downsampling. ✓✓XX

Version History

Introduced in R2024a

expand all