Trailer Body 6DOF
R2026bTrailer body with translational and rotational motion
Trailer Body 6DOF block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Vehicle Dynamics Blockset /
Vehicle Body
Description
The Trailer Body 6DOF block implements a rigid one-axle, two-axle or three-axle trailer body model that calculates longitudinal, lateral, vertical, pitch, roll, and yaw motion. The block accounts for body mass, inertia, aerodynamic drag, road incline, and weight distribution between the axle hard-point locations due to suspension and external forces and moments.
Use the Inertial Loads parameters to analyze the trailer dynamics under different loading conditions. To specify the number of trailer axles, use the Number of axles parameter.
To create additional input ports, under Input signals, select these block parameters.
Parameter | Input Port | Description |
|---|---|---|
| Rear hitch forces | Fh | Hitch force applied to the body at the rear hitch location, Fhx, Fhy, and Fhz, in the vehicle-fixed frame |
| Rear hitch moments | Mh | Hitch moment at the rear hitch location, Mhx, Mhy, and Mhz, about the vehicle-fixed frame |
Inertial Loads
To analyze the vehicle dynamics under different loading conditions, use the Inertial Loads parameters. You can specify these loads:
Front end
Overhead
Front left and front right
Rear left and rear right
Rear end
For each of the loads, you can specify the mass, location, and inertia.
The illustrations provide the load locations and vehicle parameter dimensions. The table provides the corresponding location parameter sign settings.
This table summarizes the parameter settings that specify the load locations indicated by the dots. For the location, the block uses this distance vector:
Front axle to load, along the vehicle-fixed x-axis
Vehicle centerline to load, along the vehicle-fixed y-axis
Front axle to load, along the vehicle-fixed z-axis
Load | Parameter | Example Location |
|---|---|---|
Front end | Distance vector from front axle, z1R |
|
Overhead | Distance vector from front axle, z2R |
|
Front left | Distance vector from front axle, z3R |
|
Front right | Distance vector from front axle, z4R |
|
Rear left | Distance vector from front axle, z5R |
|
Rear right | Distance vector from front axle, z6R |
|
Rear end | Distance vector from front axle, z7R |
|
Equations of Motion
To determine the vehicle motion, the block solves the rigid body dynamics equations of motion.
The Vehicle Body 6DOF Three Axles block considers the rotation of a vehicle-fixed coordinate frame about a flat earth-fixed inertial reference frame. The origin of the vehicle-fixed coordinate frame is the center of gravity of the sprung mass.
The block uses this equation to calculate the translational motion of the vehicle-fixed coordinate frame, where the applied forces [Fx Fy Fz]T are in the vehicle-fixed frame, and the mass of the body, m, is assumed to be constant.
To determine the relationship between the vehicle-fixed angular velocity vector, [p q r]T, and the rate of change of the Euler angles, , the block resolves the Euler rates into the vehicle-fixed frame.
Inverting J gives the required relationship to determine the Euler rate vector.
The applied forces and moments are the sum of the aerodynamic, gravitational, external, and suspension forces and moments.
| Calculation | Implementation |
|---|---|
Load masses and inertias | The block uses the parallel axis theorem to resolve the individual load masses and inertias with the vehicle mass and inertia. |
Gravitational forces, Fg | The block uses the direction cosine matrix (DCM) to transform the gravitational vector in the inertial-fixed frame to the vehicle-fixed frame. |
Aerodynamic forces, Fa, and moments, Ma | To determine a relative airspeed, the block subtracts the wind speed from the vehicle CG velocity. Using the relative airspeed, the block determines the aerodynamic forces. The signs for the aerodynamic terms indicate a resistive force with respect to the components of the relative wind speed. In this convention, a positive lift coefficient increases downforce (pushing the vehicle to the ground) while a negative lift coefficient generates lift (raising the vehicle upwards). Using the relative airspeed, the block determines the aerodynamic moments. |
External forces, Fin, and moments, Min | The external forces and moments are input via ports FExt and MExt. |
Suspension forces and moments | The block assumes that the suspension forces and moments act on these hardpoint locations:
|
The equations use these variables.
Vehicle CG displacement, velocity, and acceleration along the vehicle-fixed x-axis | |
Vehicle CG displacement, velocity, and acceleration along the vehicle-fixed y-axis | |
Vehicle CG displacement, velocity, and acceleration along the vehicle-fixed z-axis | |
φ | Rotation of the vehicle-fixed frame about the earth-fixed X-axis (roll) |
θ | Rotation of the vehicle-fixed frame about the earth-fixed Y-axis (pitch) |
ψ | Rotation of the vehicle-fixed frame about the earth-fixed Z-axis (yaw) |
| FFLx, FFLy, FFLz | Suspension forces applied to the front left hardpoint along the vehicle-fixed x-, y-, and z-axes |
| FFRx, FFRy, FFRz | Suspension forces applied to the front right hardpoint along the vehicle-fixed x-, y-, and z-axes |
| FMLx, FMLy, FMLz | Suspension forces applied to the middle left hardpoint along the vehicle-fixed x-, y-, and z-axes |
| FMRx, FMRy, FMRz | Suspension forces applied to the middle right hardpoint along the vehicle-fixed x-, y-, and z-axes |
| FRLx, FRLy, FRLz | Suspension forces applied to the rear left hardpoint along the vehicle-fixed x-, y-, and z-axes |
| FRRx, FRRy, FRRz | Suspension forces applied to the rear right hardpoint along the vehicle-fixed x-, y-, and z-axes |
| MFLx, MFLy, MFLz | Suspension moment applied to the front left hardpoint about the vehicle-fixed x-, y-, and z-axes |
| MFRx, MFRy, MFRz | Suspension moment applied to the front right hardpoint about the vehicle-fixed x-, y-, and z-axes |
| MMLx, MMLy, MMLz | Suspension moment applied to the middle left hardpoint about the vehicle-fixed x-, y-, and z-axes |
| MMRx, MMRy, MMRz | Suspension moment applied to the middle right hardpoint about the vehicle-fixed x-, y-, and z-axes |
| MRLx, MRLy, MRLz | Suspension moment applied to the rear left hardpoint about the vehicle-fixed x-, y-, and z-axes |
| MRRx, MRRy, MRRz | Suspension moment applied to the rear right hardpoint about the vehicle-fixed x-, y-, and z-axes |
| Fextx, Fexty, Fextz | External forces applied to the vehicle CG along the vehicle-fixed x-, y-, and z-axes |
| Fdx, Fdy, Fdz | Aerodynamic forces applied to the vehicle CG along the vehicle-fixed x-, y-, and z-axes |
| Mextx, Mexty, Mextz | External moments applied to the vehicle CG about the vehicle-fixed x-, y-, and z-axes |
| Mdx, Mdy, Mdz | Aerodynamic moments applied to the vehicle CG about the vehicle-fixed x-, y-, and z-axes |
| I | Vehicle body moments of inertia |
| a, b, c | Distance of the front, middle, and rear axles, respectively, from the normal projection point of the vehicle CG onto the common axle plane |
| h | Height of the vehicle CG above the axle plane |
| d | Lateral distance from the geometric centerline to the center of mass along the vehicle-fixed y-axis |
hh_f, hh_r | Height of the front and rear hitches, respectively, above the axle plane along the vehicle-fixed z-axis |
dh_f, dh_r | Longitudinal distance of the front and rear hitches, respectively, from the normal projection point of the vehicle CG onto the common axle plane |
hl_f, hl_r | Lateral distance from center of mass to the front and rear hitches, respectively, along the vehicle-fixed y-axis |
| wF, wM, wR | Front, middle, and rear track widths, respectively |
| Cd | Aerodynamic drag force coefficient acting along the vehicle-fixed x-axis |
| Cs | Aerodynamic side force coefficient acting along the vehicle-fixed y-axis |
| Cl | Aerodynamic lift force coefficient acting along the vehicle-fixed z-axis |
| Crm | Aerodynamic roll moment coefficient acting about the vehicle-fixed x-axis |
| Cpm | Aerodynamic pitch moment coefficient acting about the vehicle-fixed y-axis |
| Cym | Aerodynamic yaw moment coefficient acting about the vehicle-fixed z-axis |
| Af | Frontal area |
| R | Atmospheric specific gas constant |
| T | Environmental air temperature |
| Pabs | Environmental absolute pressure |
| wx, wy, wz | Wind velocity along the vehicle-fixed x-, y-, and z-axes |
| Wx, Wy, Wz | Wind velocity along inertial X-, Y-, and Z-axes |
Examples
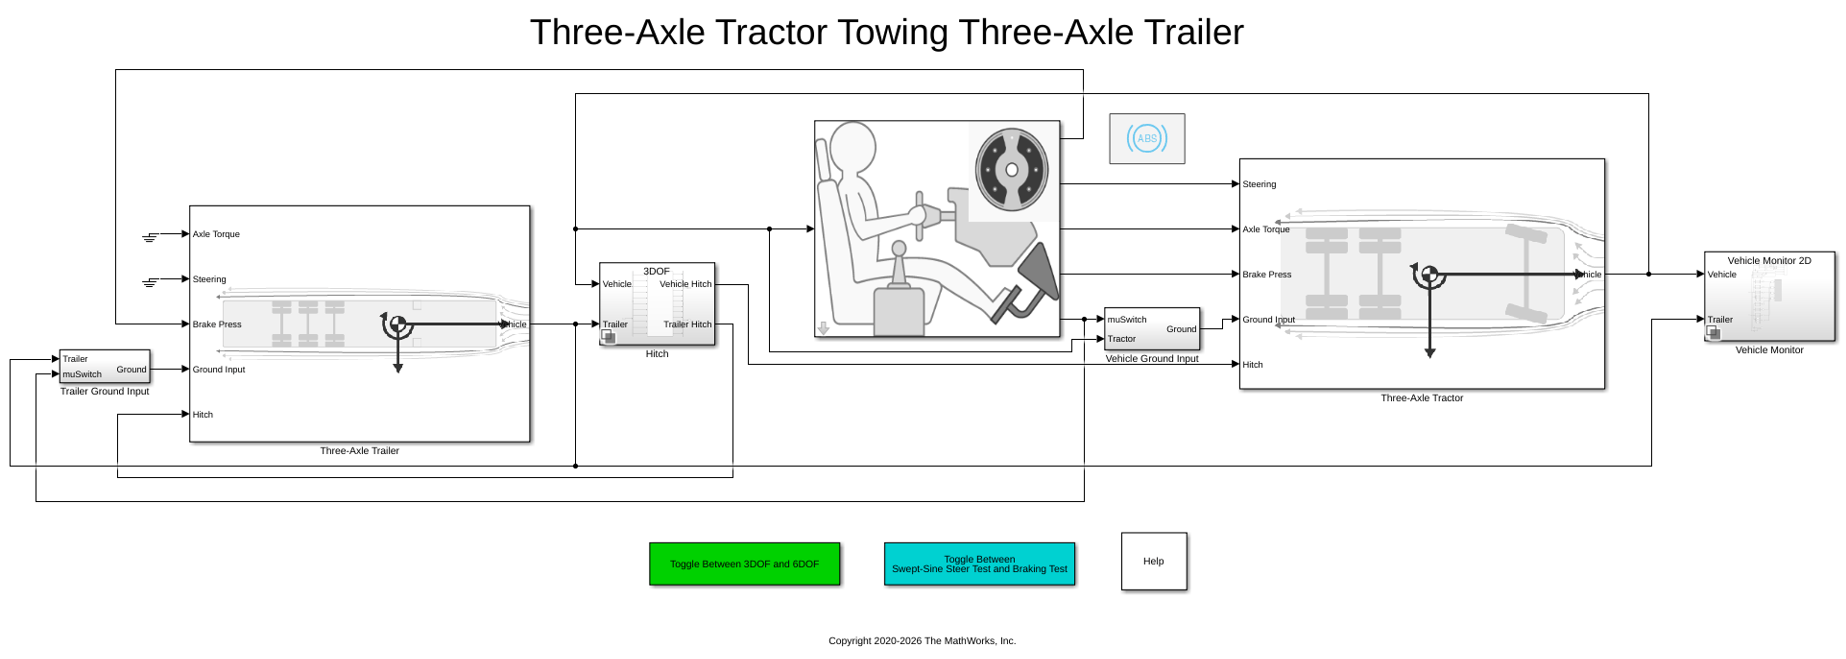
Three-Axle Tractor Towing a Three-Axle Trailer
Simulates three-axle tractor towing a three-axle trailer for commercial trucking applications. Implements hitch subsystem, sinusoidal wave steering or braking test, and axle torque applied to tractor rear wheels.
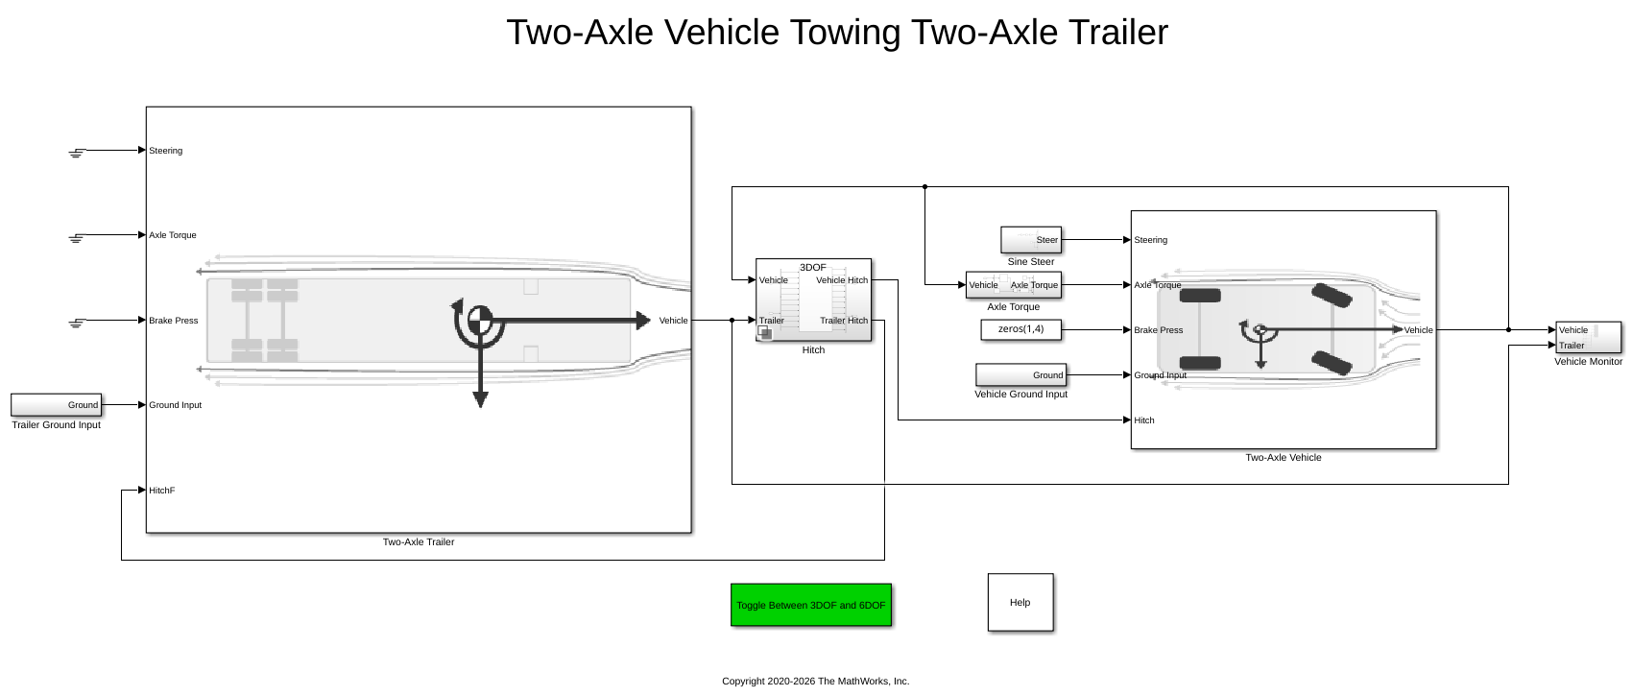
Two-Axle Tractor Towing a Two-Axle Trailer
Simulate a two-axle tractor towing a two-axle trailer for a commercial trucking application. Model implements a hitch subsystem, sinusoidal wave steering input, and an axle torque applied to the rear wheels of the tractor.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"vehdynlibeom/Trailer Body 6DOF"
Example: add_block("vehdynlibeom/Trailer Body 6DOF","myModel/myBlock",MakeNameUnique="on")
For information about programmatic access to individual block parameters, see the Programmatic Use section of parameter descriptions on this page.
References
[1] Gillespie, Thomas. Fundamentals of Vehicle Dynamics. Warrendale, PA: Society of Automotive Engineers (SAE), 1992.
Extended Capabilities
Version History
Introduced in R2020b

