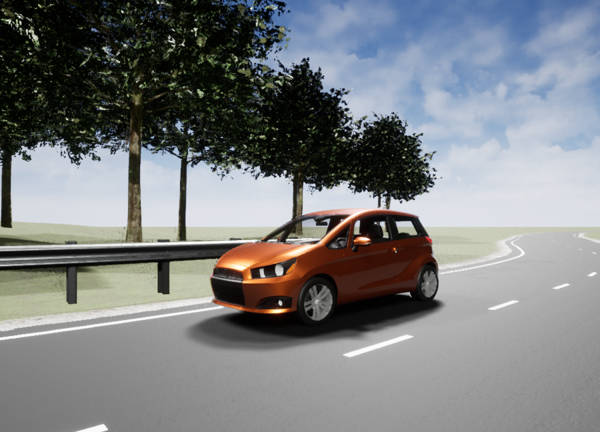
Vehicle Path Tracking Using Model Predictive Control (MPC)
This submission contains a model to show the implementation of MPC on a vehicle moving in a US Highway scene.
https://github.com/mathworks/vehicle-model-predictive-control
引用格式
MathWorks Student Competitions Team (2026). Vehicle Path Tracking Using Model Predictive Control (MPC) (https://github.com/mathworks/vehicle-model-predictive-control/releases/tag/v1.0.2), GitHub. 检索时间: .

| 版本 | 已发布 | 发行说明 | Action |
|---|---|---|---|
| 1.0.2 | See release notes for this release on GitHub: https://github.com/mathworks/vehicle-model-predictive-control/releases/tag/v1.0.2 |
||
| 1.0.1 | See release notes for this release on GitHub: https://github.com/mathworks/vehicle-model-predictive-control/releases/tag/v1.0.1 |
||
| 1.0.0 |
要查看或报告此来自 GitHub 的附加功能中的问题,请访问其 GitHub 存储库。
要查看或报告此来自 GitHub 的附加功能中的问题,请访问其 GitHub 存储库。

