Non-Isolated DC-DC Converter Controller Design Workflow
R2026bNon-Isolated DC-DC Converter Controller Design Workflow
This example shows the end-to-end workflow for designing, validating, and deploying a voltage controller for a non-isolated DC-DC converter, starting from a set of converter parameters and ending with a controller that is validated in simulation, robust across the operating envelope, and deployable to a Texas Instruments® C2000™ F28379D LaunchPad™ paired with the BOOSTXL-BUCKCONV power stage.
The workflow is arranged in four stages: model configuration and closed-loop simulation, online frequency response estimation (FRE), stability and sensitivity analysis, and hardware FRE. These stages share a common set of parameters and gains that flow through subsystem references and MAT-file data stores, so a single edit in the plant or controller definition propagates automatically into every downstream stage.
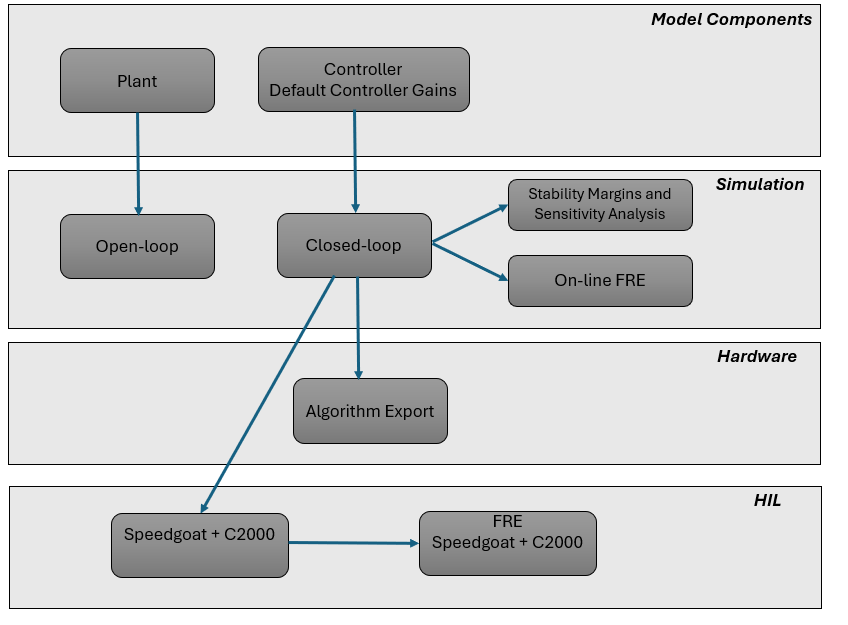
Non-Isolated DC-DC Converter Control Design Steps
Each stage is a separate live script, accessible from a project shortcut on the MATLAB® toolstrip. The example series consists of these steps:
Configure and Simulate Non-Isolated DC-DC Converter Controller
Estimate Online Frequency Response of Non-Isolated DC-DC Converter
Verify Stability Margins and Analyze Sensitivity for Non-Isolated DC-DC Converter
Validate Controller Gains with Frequency Response Estimation on Hardware
Open the Non-Isolated DC-DC Converter Project
The BuckBoostExample.prj project file contains the reference application, which consists of the Simscape™ Electrical™ plant subsystem references for the Buck, Boost, and Buck-Boost topologies, the voltage controller subsystem reference, the ctrlData.mat gains data store, all supporting utilities, and the toolstrip project shortcuts that open the live script for each stage of this workflow. Open the project file by running this code.
prj = openProject("buckboostworkflow");Open the BuckVoltageControlSim.slx Simulink® model.
open_system("BuckVoltageControlSim");The BuckVoltageControlSim.slx model is the entry point for the closed-loop desktop simulation and contains the following top-level components, which you can customize in accordance with your design:
Converter plant. Subsystem reference that models the power stage of the Buck, Boost, or Buck-Boost converter topology using Simscape Electrical. The active topology and operating parameters are set through the
getNonIsoDCDCConvParamfunction.Voltage controller. Subsystem reference at
~\ModelComponents\Controller\NonIsoConvVoltageController.slxthat implements the voltage control loop. Supports proportional-integral (PI) and Type-2 compensators, selectable through theGainsSelectormask parameter.Controller gains data store.
ctrlData.matin~\Data\stores the default gains produced by the analytical design and any custom gains tuned by hand or refined through FRE, so every downstream stage reads from the same file.Project shortcuts. Toolstrip buttons that open the live script for each stage of the workflow, along with supporting shortcuts for parameterization and post-processing.
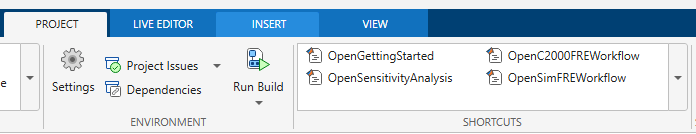
For the first stage of the workflow, which configures the converter parameters and controller gains and runs the closed-loop simulation, click the Configure and Simulate project shortcut.
Workflow Steps
To learn more about each step in the workflow, see:

