帧到采样的转换
R2026b优化并减少在图像处理、数字信号处理和雷达应用等领域使用大型输入的算法的 I/O。要优化设计所需的 I/O,请使用帧到采样的转换、多采样处理或 I/O 阈值。
函数
hdl.npufun | Apply neighborhood processing and element-wise operations to incoming image or matrix for frame-to-sample conversion (自 R2022b 起) |
hdl.iterfun | Reduce frame-based data to frame-level characteristics (自 R2026b 起) |
模型设置
模块
 | Neighborhood Processing Subsystem | Create algorithm that follows the neighborhood pattern (自 R2022b 起) |
主题
- HDL Code Generation from Frame-Based Algorithms
Generate synthesizable HDL code from frame-based algorithms by using the HDL Coder™ frame-to-sample conversion to target sample-based and pixel-based hardware and reduce I/O consumption and prototyping times.
- Optimize Area Usage for Frame-Based Algorithms with Tall Array Inputs
Generate area efficient HDL code from a frame-based algorithm that has input data with significantly more rows than columns.
- Generate HDL Code from Frame-Based Models by Using Neighborhood Modeling Methods
Generate HDL code from frame-based models by using MATLAB Function blocks or the Neighborhood Processing Subsystem block.
- Use Sample-Based Inputs and Frame-Based Inputs in an Algorithm
Generate HDL code from an algorithm that uses both sample-based and frame-based inputs.
- Use Neighborhood, Reduction, and Iterator Patterns with a Frame-Based Model or Function for HDL Code Generation
Generate HDL code from a frame-based design that models neighborhood, reduction, and iterator patterns.
精选示例
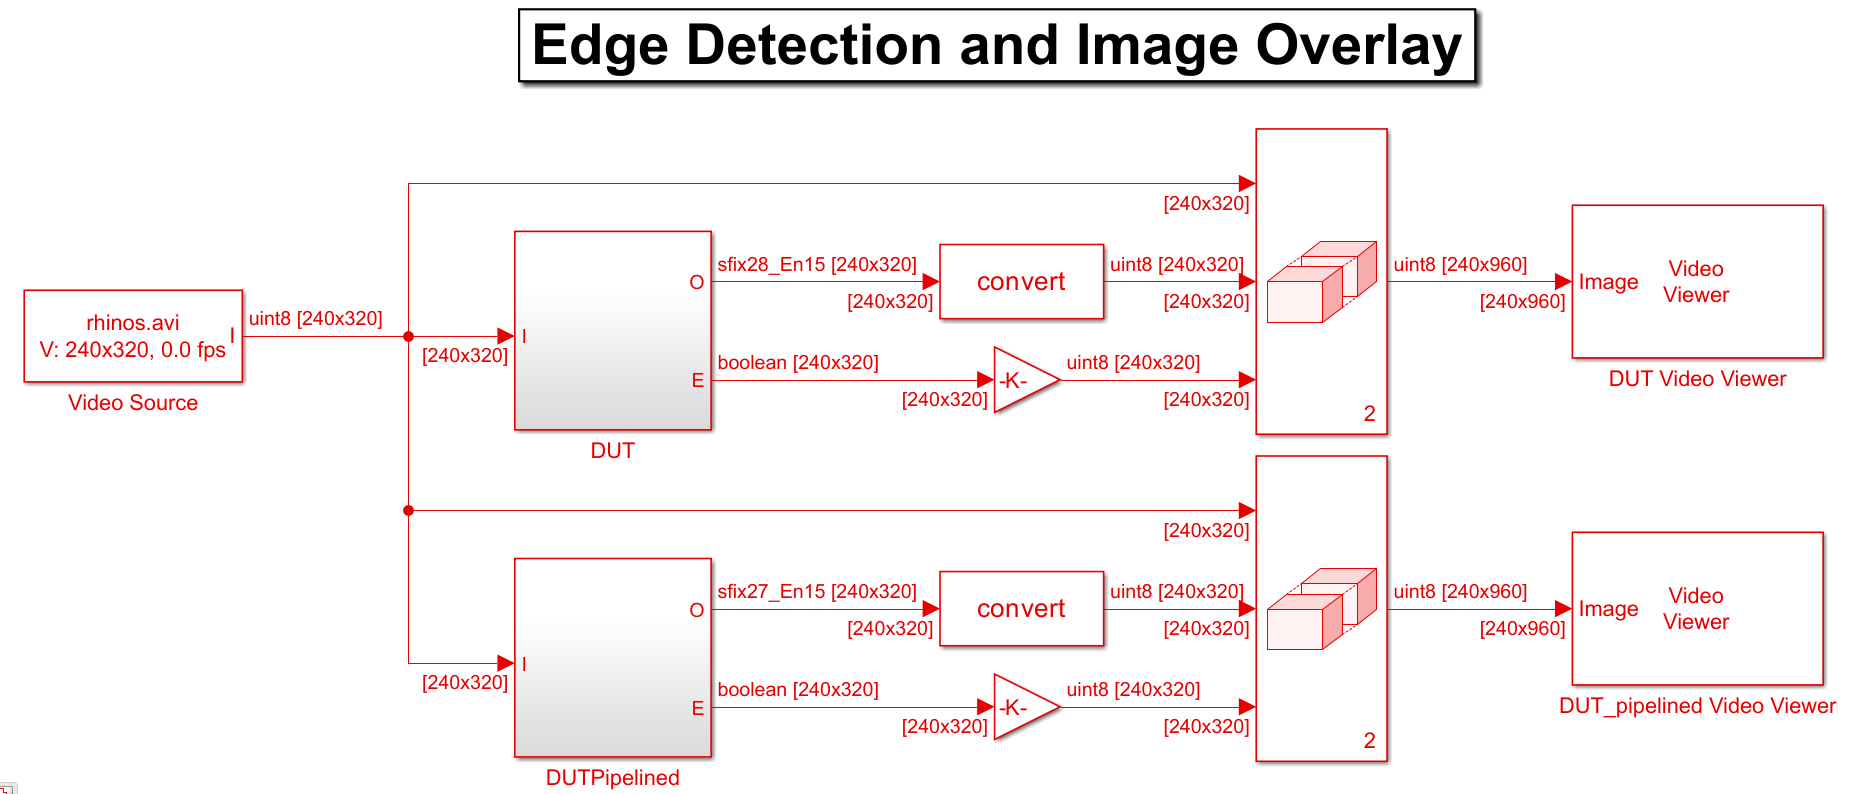
Synthesize Code for Frame-Based Model
Generate HDL code for a Sobel edge detection frame algorithm and calculate the frames per second of your design by synthesizing the generated code with the Simulink® HDL Workflow Advisor.
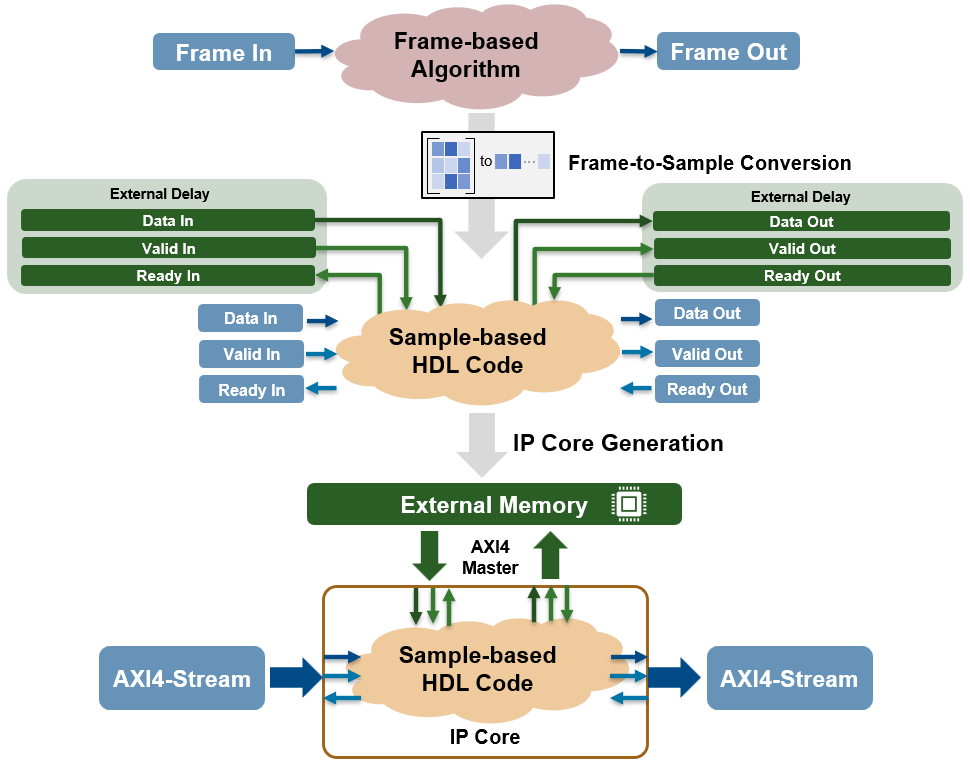
Offload Large Delays from Frame-Based Models to External Memory
Map large delays to external memory when generating an IP core from a frame-based algorithm.
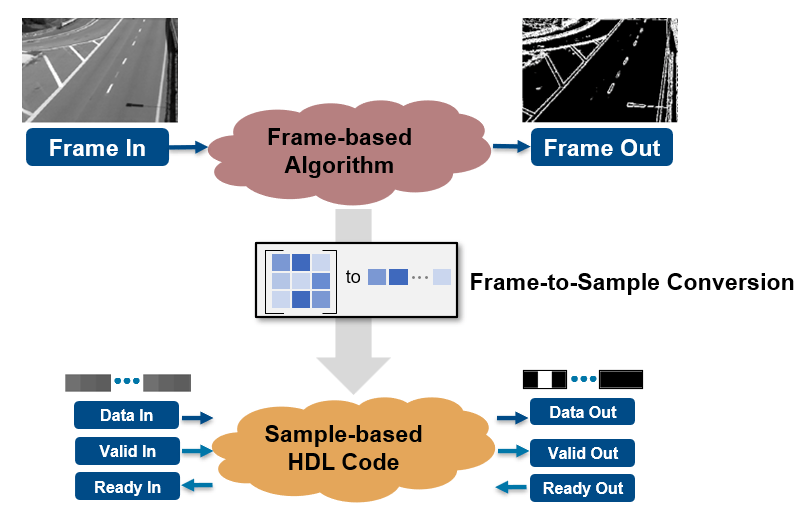
Generate IP Core for Frame-Based Model with AXI4 Stream Interfaces
Leverage the frame to sample optimization from HDL Coder™ to generate a sample-based IP core with AXI4-Stream interfaces from a frame-based Simulink® model. The generated IP core can then be deployed to hardware and verified using live streaming data from MATLAB®.
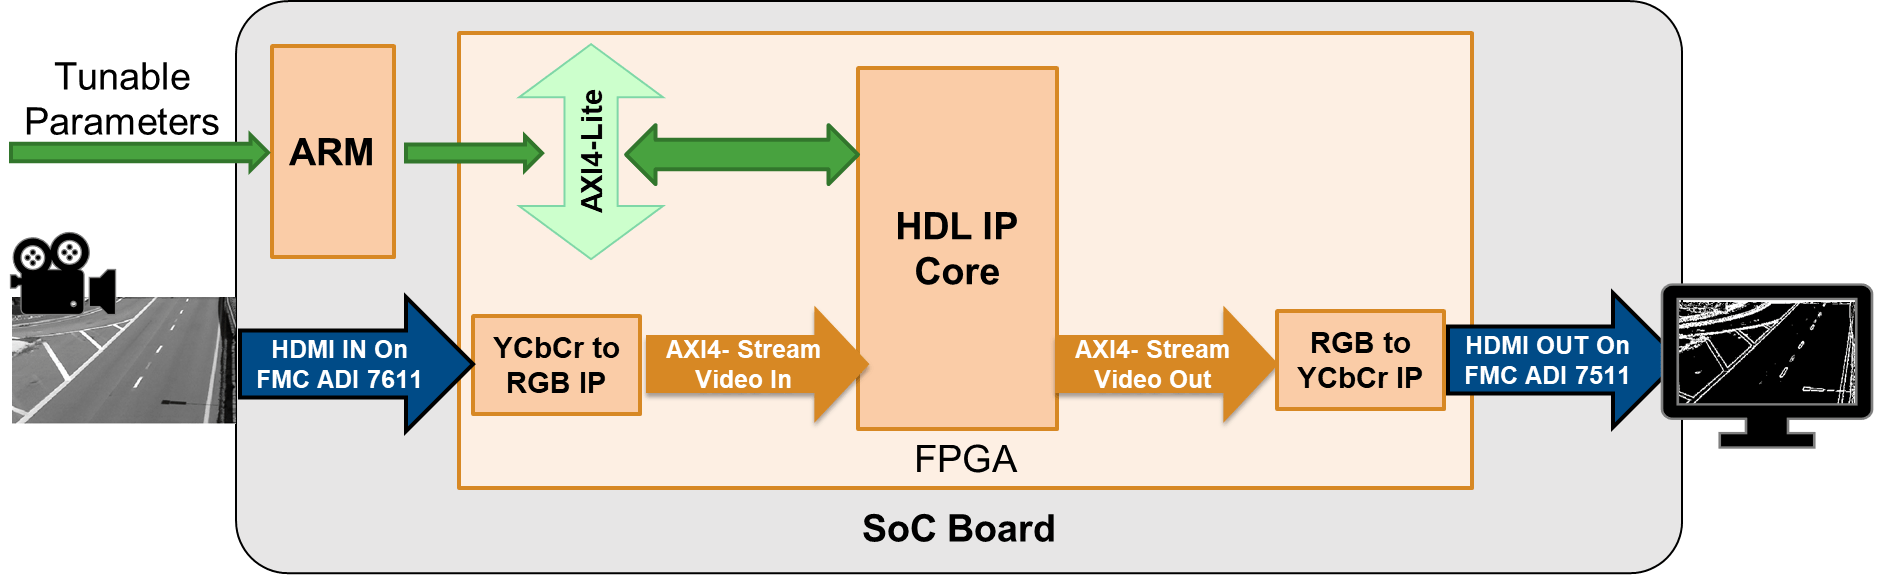
Generate IP Core from Frame-Based Model with AXI4 Stream Video Interface
You can use the HDL Coder™ frame-to-sample optimization to design and deploy frame-based algorithms that use AXI4-Stream Video interfaces to enable high-speed video streaming.
Compute Image Characteristics with a Frame-Based Model for HDL Code Generation
Use frame-based modeling to model an image processing algorithm to detect an object based on color.
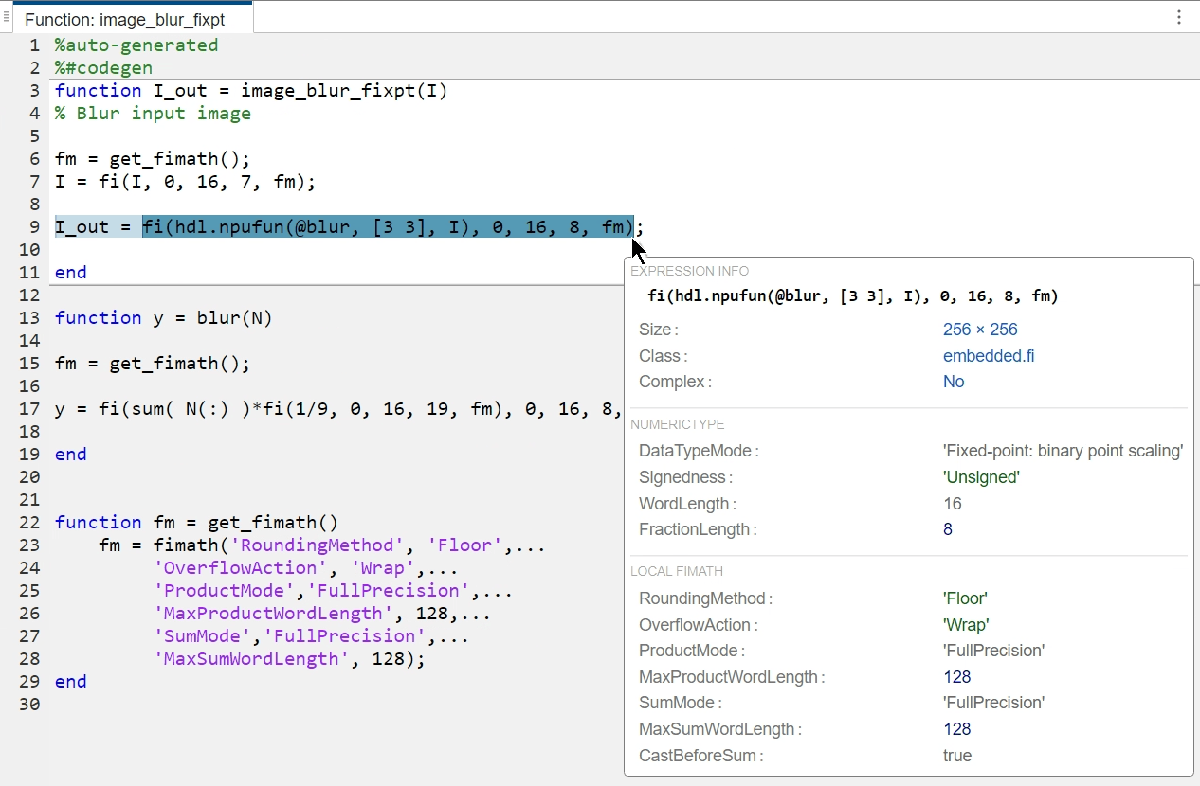
Convert Frame-Based Model to Fixed Point and Generate HDL Code
Use the Fixed-Point Tool to convert the data types in a frame-based model to fixed-point and generate HDL code using frame-to-sample conversion.
Generate HDL Code from Frame-Based Model by Using Neighborhood Processing with Row and Column Inputs
Generate HDL code for a frame-based model to convert Bayer pattern encoding to true color imaging.
Generate HDL IP Core for Frame-Based MATLAB Function with AXI4-Stream Interfaces
Generate a sample-based HDL IP core with AXI4-Stream interfaces from a frame-based MATLAB function by using the frame-to-sample optimization, and verify the IP core on a ZedBoard.

