主要内容

Moving Coil Speaker

R2026b

Model of moving coil speaker with nonlinear elements

Since R2026b

  • Moving Coil Speaker block

Libraries:
Simscape Acoustics / Applications / Moving Coil Speakers

Description

Add-On Required: This feature requires the Simscape Acoustics add-on.

This block models the electrical, mechanical, and acoustic elements of a moving coil loudspeaker. The block has electrical conserving ports for the electrical signal that drives the voice coil, acoustic conserving ports for the speaker radiation and enclosure, and an optional mechanical translational conserving port for the mass of the nonmoving speaker components.

The Moving Coil Speaker block models the physical properties of a loudspeaker by implementing an equivalent circuit using Simscape™ blocks from the electrical, mechanical translational, and acoustic domains. By default, the block models a linear moving coil speaker. The figure shows the equivalent circuit using the following Simscape blocks in each domain:

  • Electrical: The Moving Coil Speaker block models heating losses in the voice coil using a Resistor (Simscape) block. The block models magnetic energy stored from the coil turns using an Inductor (Simscape) block. The resistance and inductance values depend on wire material, diameter, length, turn radius, number of turns, and other physical properties of the modeled speaker.

  • Mechanical Translational: The Moving Coil Speaker block models the total mass of the moving speaker using a Mass (Simscape) block. The block models speaker stiffness using a Translational Spring (Simscape) block. Mechanical friction in the speaker is modeled using a Translational Damper (Simscape) block.

  • Transducers: Current through the voice coil creates a magnetic force that moves the speaker cone. The Moving Coil Speaker block models this interaction using a Translational Electromechanical Converter (Simscape) block. Cone movement causes compression and rarefaction in air molecules. The block models this interaction using a Mechanical to Acoustic Converter block.
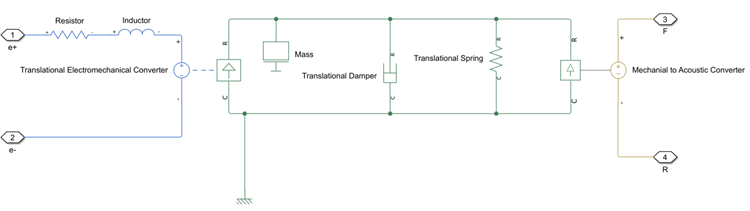
Equivalent circuit to the Moving Coil Speaker block as a Simscape model. The circuit does not include any of the available nonlinearities, eddy effects, or thermal effects.

You can also use the Moving Coil Speaker block to model the following physical properties of a moving coil speaker:

  • Electrical effects caused by eddy currents in conductive elements of the loudspeaker near the voice coil

  • Nonlinearities in the electromechanical converter

  • Mechanical nonlinearities caused by stiffness in the speaker suspension

  • Mechanical nonlinearities caused by damping from viscous friction

  • Electrical and electromagnetic effects caused by temperature changes in the speaker

Each additional physical property you model changes the equivalent circuit that the block implements. The figure shows the equivalent circuit of a moving coil speaker with all of the physical properties from the list. The labeled Simscape blocks indicate changes from the linear equivalent circuit.
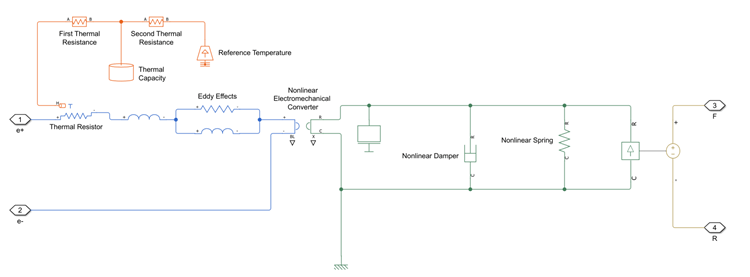
Equivalent circuit to the Moving Coil Speaker block as a Simscape model. All nonlinearities are enabled.

Examples

Ports

Output

expand all

Physical signal output for the force factor measurement.

Dependencies

To enable this port, select the Nonlinear BL parameter.

Physical signal output for the mechanical stiffness measurement.

Dependencies

To enable this port, select the Nonlinear mechanical stiffness parameter.

Physical signal output for the mechanical damping measurement.

Dependencies

To enable this port, select the Nonlinear mechanical damping parameter.

Physical signal output for the speaker excursion.

Dependencies

To enable this port, select the Include motion sensor ports parameter.

Physical signal output for the speaker velocity.

Dependencies

To enable this port, select the Include motion sensor ports parameter.

Physical signal output for the temperature of the speaker coil.

Dependencies

To enable this port, select the Model thermal effects parameter.

Physical signal output for the temperature of the speaker magnet.

Dependencies

To enable this port, select the Model thermal effects parameter.

Conserving

expand all

Electrical conserving port associated with the speaker positive terminal. Connect this port to the electrical signal driving the speaker.

Electrical conserving port associated with the speaker negative terminal. Connect this port to the electrical signal driving the speaker.

Acoustic conserving port associated with the front of the speaker. This port is typically connected to a radiation impedance, such as the Circular Piston Radiation Impedance block.

Acoustic conserving port associated with the rear of the speaker. This port is typically connected to an acoustic enclosure, such as the Ported Speaker Enclosure block.

Mechanical translational conserving port associated with the speaker mass. You can connect this port to elements that model the mass of the nonmoving parts of the speaker.

Dependencies

To enable this port, select the Include mechanical port parameter.

Parameters

expand all

Parameters

Electrical resistance of the speaker coil.

Electrical inductance of the speaker coil.

Mass of the moving speaker body.

Area of the speaker cone.

Inductance

Option to model eddy effects on the electrical components of the speaker.

Resistance value of the eddy current.

Dependencies

To enable this parameter, select the Model eddy current effects parameter.

Inductance value of the eddy current.

Dependencies

To enable this parameter, select the Model eddy current effects parameter.

Force Factor

Force factor (Bl product) of the speaker electromechanical transducer. If you select the Nonlinear BL parameter, this parameter is the constant value of the force factor polynomial.

Option to model nonlinear force factor as a polynomial function of displacement. To enable the BL port, select this parameter.

Coefficient for the first-order term of the force factor polynomial.

Dependencies

To enable this parameter, select the Nonlinear BL parameter.

Coefficient for the second-order term of the force factor polynomial.

Dependencies

To enable this parameter, select the Nonlinear BL parameter.

Coefficient for the third-order term of the force factor polynomial.

Dependencies

To enable this parameter, select the Nonlinear BL parameter.

Coefficient for the fourth-order term of the force factor polynomial.

Dependencies

To enable this parameter, select the Nonlinear BL parameter.

Coefficient for the fifth-order term of the force factor polynomial.

Dependencies

To enable this parameter, select the Nonlinear BL parameter.

Mounting Stiffness

Stiffness, or spring rate, of the speaker suspension. If you select the Nonlinear mechanical stiffness parameter, this parameter is the constant value of the stiffness polynomial.

Option to model nonlinear mechanical stiffness as a polynomial function of displacement. To enable the K port, select this parameter.

Coefficient for the first-order term of the stiffness polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical stiffness parameter.

Coefficient for the second-order term of the stiffness polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical stiffness parameter.

Coefficient for the third-order term of the stiffness polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical stiffness parameter.

Coefficient for the fourth-order term of the stiffness polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical stiffness parameter.

Coefficient for the fifth-order term of the stiffness polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical stiffness parameter.

Mechanical Damping

Mechanical damping coefficient modeling viscous friction in the speaker. If you select the Nonlinear mechanical damping parameter, this parameter is the constant value of the damping polynomial.

Option to model nonlinear mechanical damping as a polynomial function of velocity. To enable the D port, select this parameter.

Coefficient for the first-order term of the damping polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical damping parameter.

Coefficient for the second-order term of the damping polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical damping parameter.

Coefficient for the third-order term of the damping polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical damping parameter.

Coefficient for the fourth-order term of the damping polynomial.

Dependencies

To enable this parameter, select the Nonlinear mechanical damping parameter.

Mechanical Ports

Option to include a mechanical translational port for connecting to external mechanical elements. To enable the M port, select this parameter.

Option to include physical signal output ports for speaker excursion and velocity. To enable the X and V ports, select this parameter.

Thermal

Option to model thermal effects of the speaker coil. To enable the Tcoil and Tmag ports, select this parameter.

Ambient temperature of the speaker coil.

Dependencies

To enable this parameter, select the Model thermal effects parameter.

Thermal capacity of the speaker coil.

Dependencies

To enable this parameter, select the Model thermal effects parameter.

Temperature coefficient of resistance of the coil.

Dependencies

To enable this parameter, select the Model thermal effects parameter.

Thermal resistance between the speaker coil and suspension.

Dependencies

To enable this parameter, select the Model thermal effects parameter.

Thermal capacity of the speaker magnets.

Dependencies

To enable this parameter, select the Model thermal effects parameter.

Thermal resistance between the speaker coil and the speaker basket.

Dependencies

To enable this parameter, select the Model thermal effects parameter.

Version History

Introduced in R2026b